An Inspiring Visual Tour of Combining Exosuit With Short-Swiped Feedback
Design and Control of Soft BioMechatronic Exosuits for Personalized ...
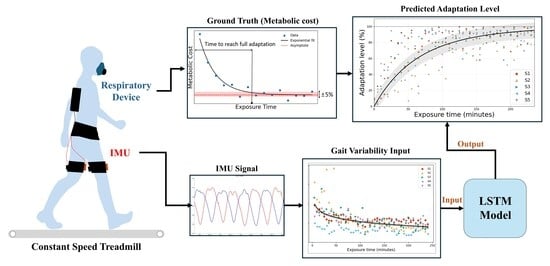
The integration of physiological feedback into control loops fosters neuroplasticity and active patient engagement. This research contributes to the advancement of soft wearable robotics as a viable, patient-centric tool for in-home and clinical gait rehabilitation, offering a promising path toward functional recovery.
Exoskeleton robots hold great promise for stroke rehabilitation with upper limb impairments. However, conventional motion-based exoskeletons often fall short by lacking brain-driven control, limiting user engagement, and providing insufficient support for motor learning and neuroplasticity.
Combining Exosuit With Short-Swiped Feedback
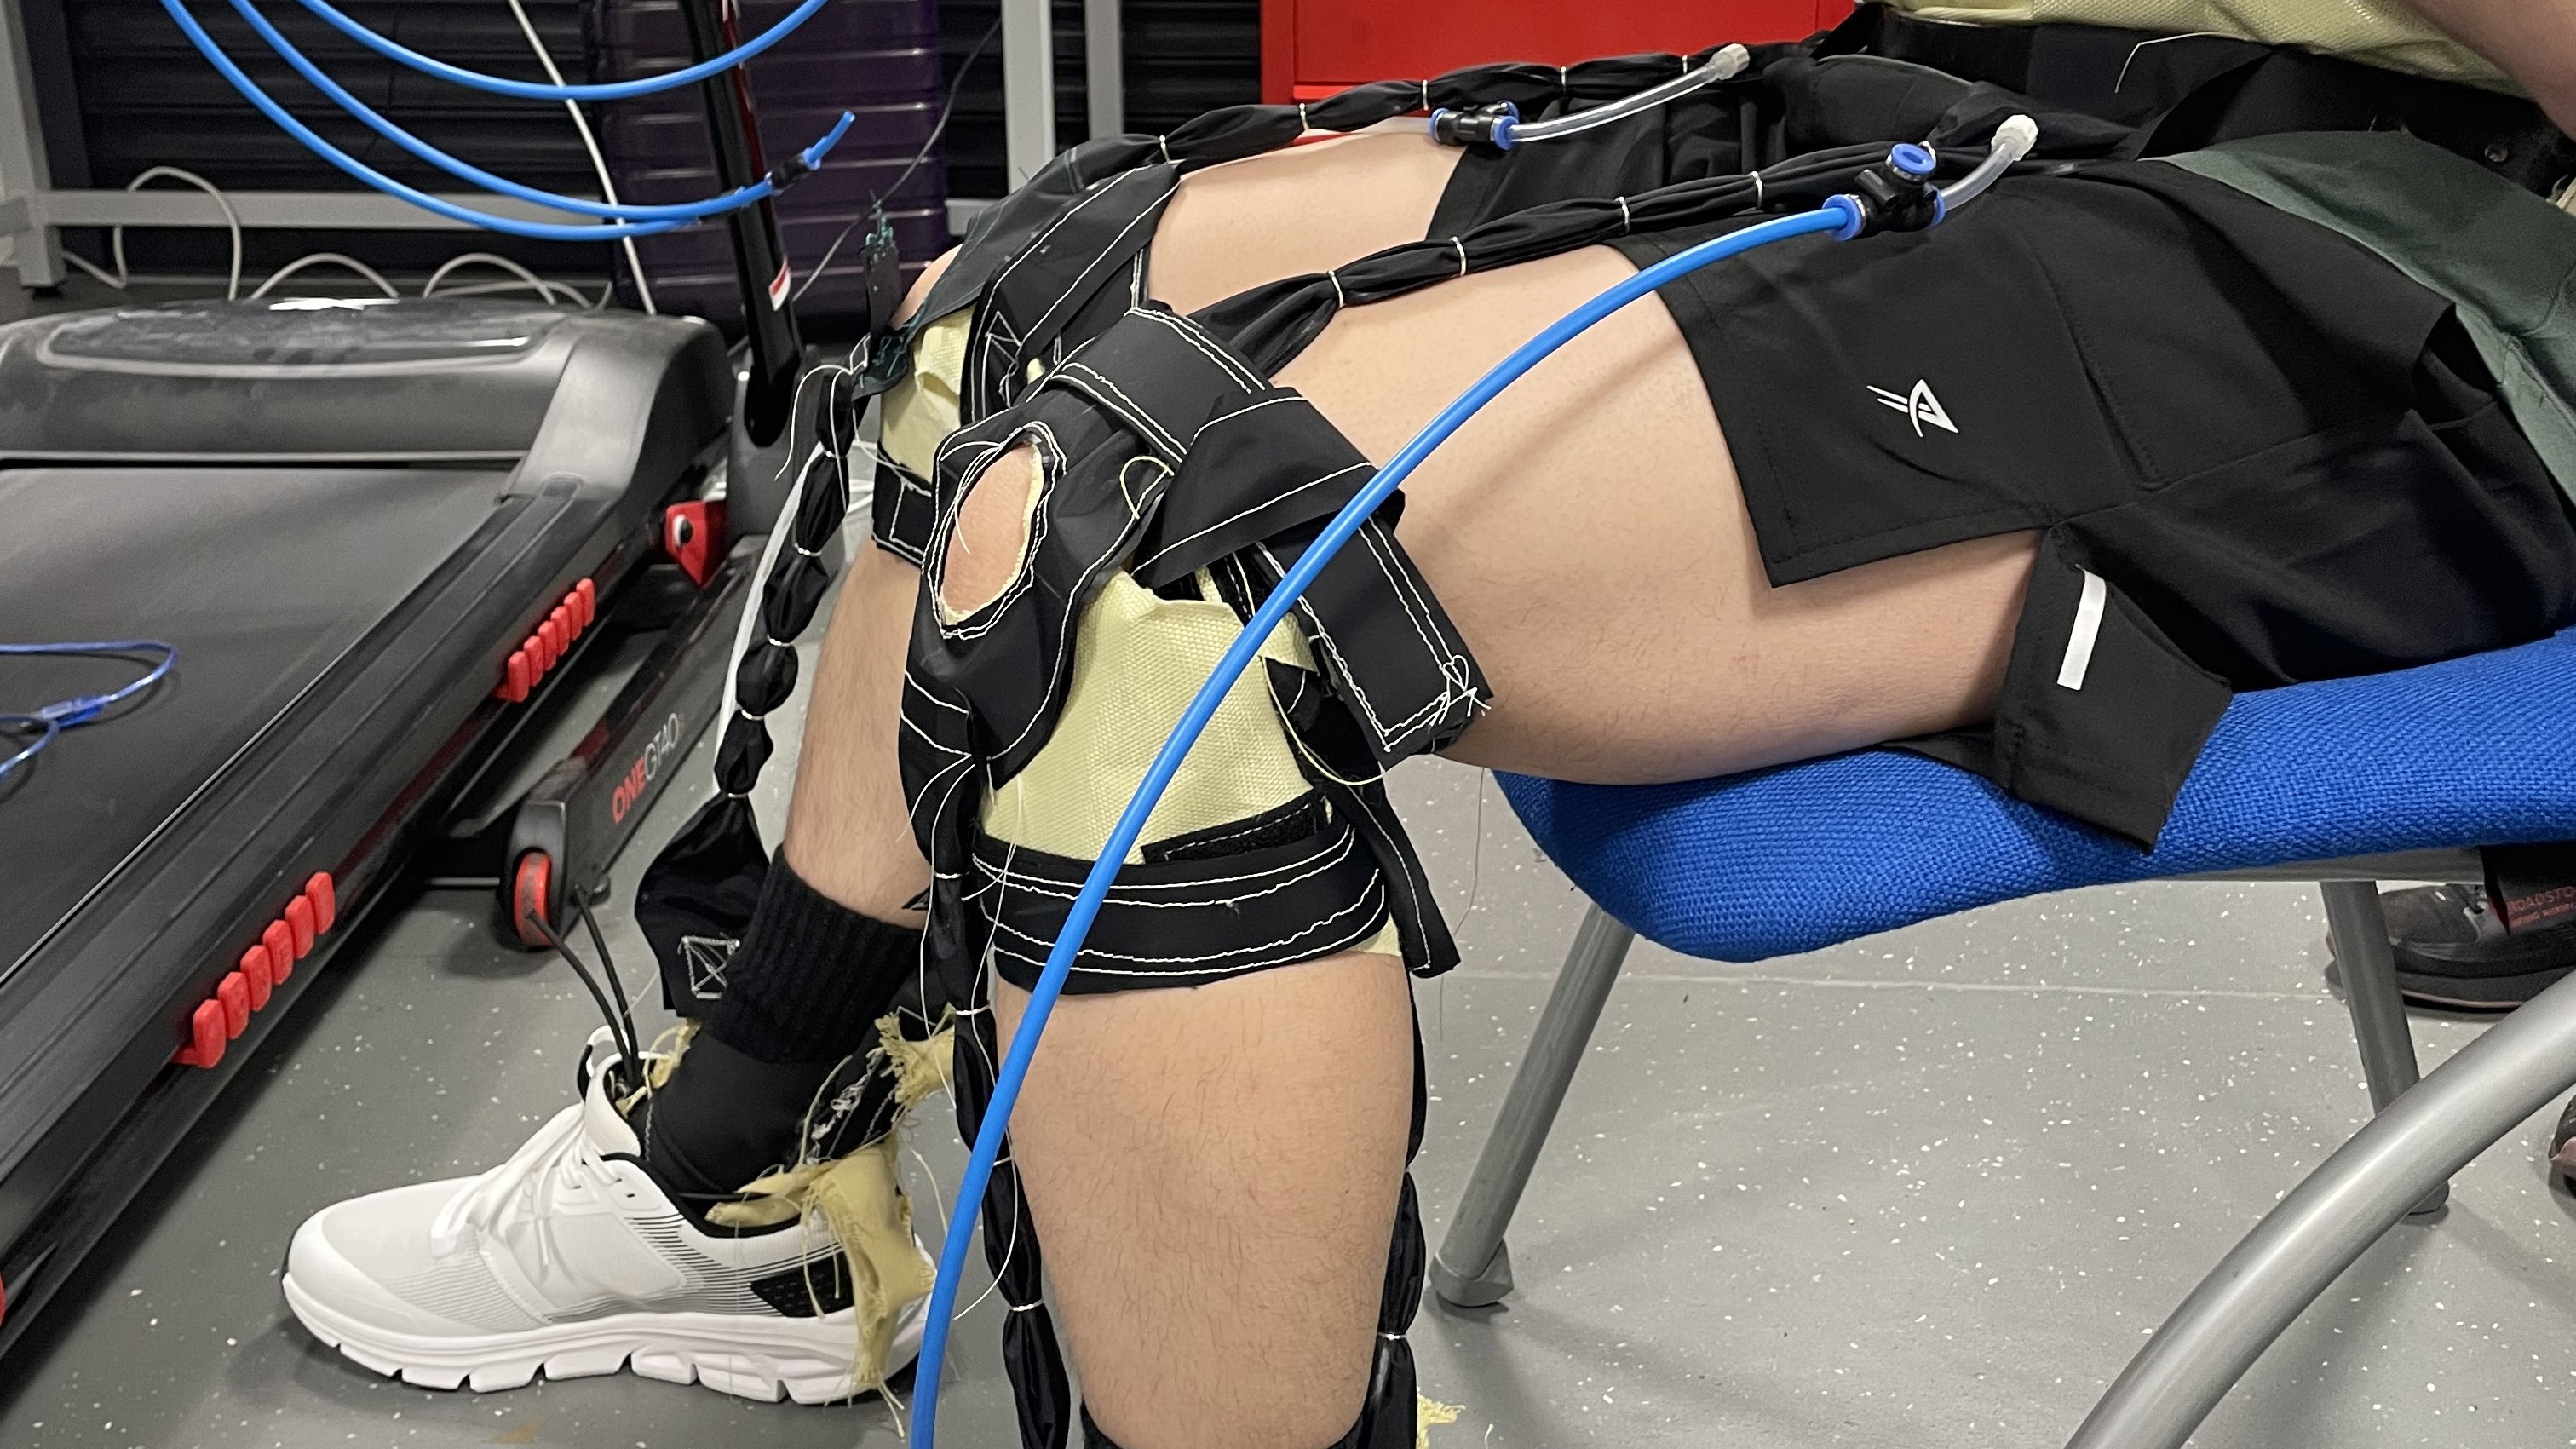
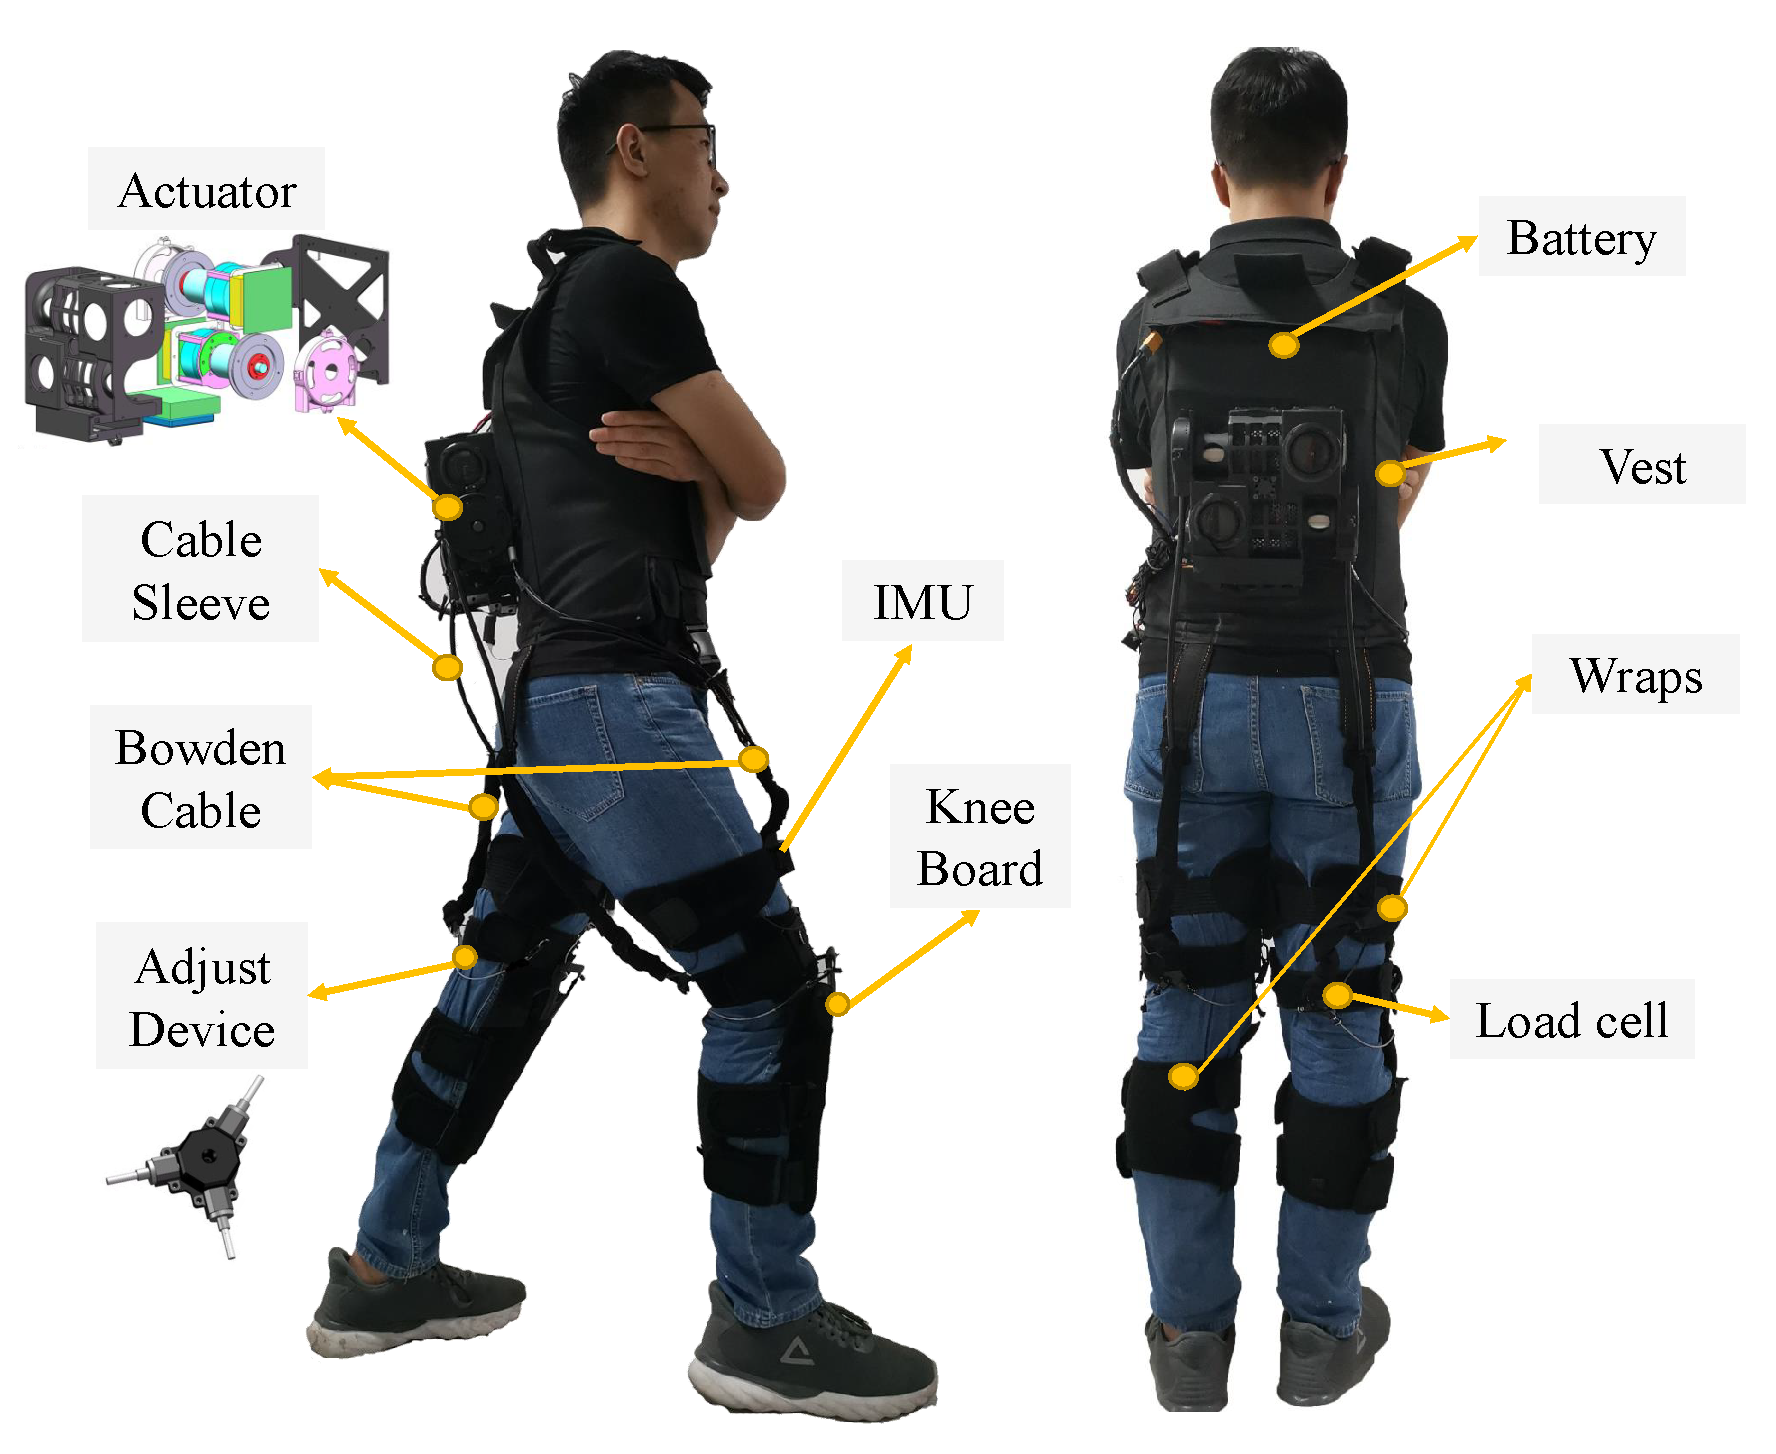
We study to what extent the active exosuit is assisting the human by analyzing gait dynamics and kinetics (joint moments, power, force delivered by the exosuit ). Inverse dynamics is an effective way to determine to what degree the exosuit is augmenting the body function at a joint level.
Design, modeling, and demonstration of a new dual
Combining Exosuit With Short-Swiped Feedback
Moving forward, it's essential to keep these visual contexts in mind when discussing Combining Exosuit With Short-Swiped Feedback.
The first test (Section " Exosuit Assistance Demonstration") sought to confirm that the extensible exosuit in engaged mode (i.e., extended mechanism) could provide the same torque assistance but with reduced device-to-body forces ( on the shoulders and legs) compared to the form-fitting exosuit during a manual lifting task.
Perceptually guided Bayesian optimization enables assistance customization for a back exosuit that supports lifting activities.