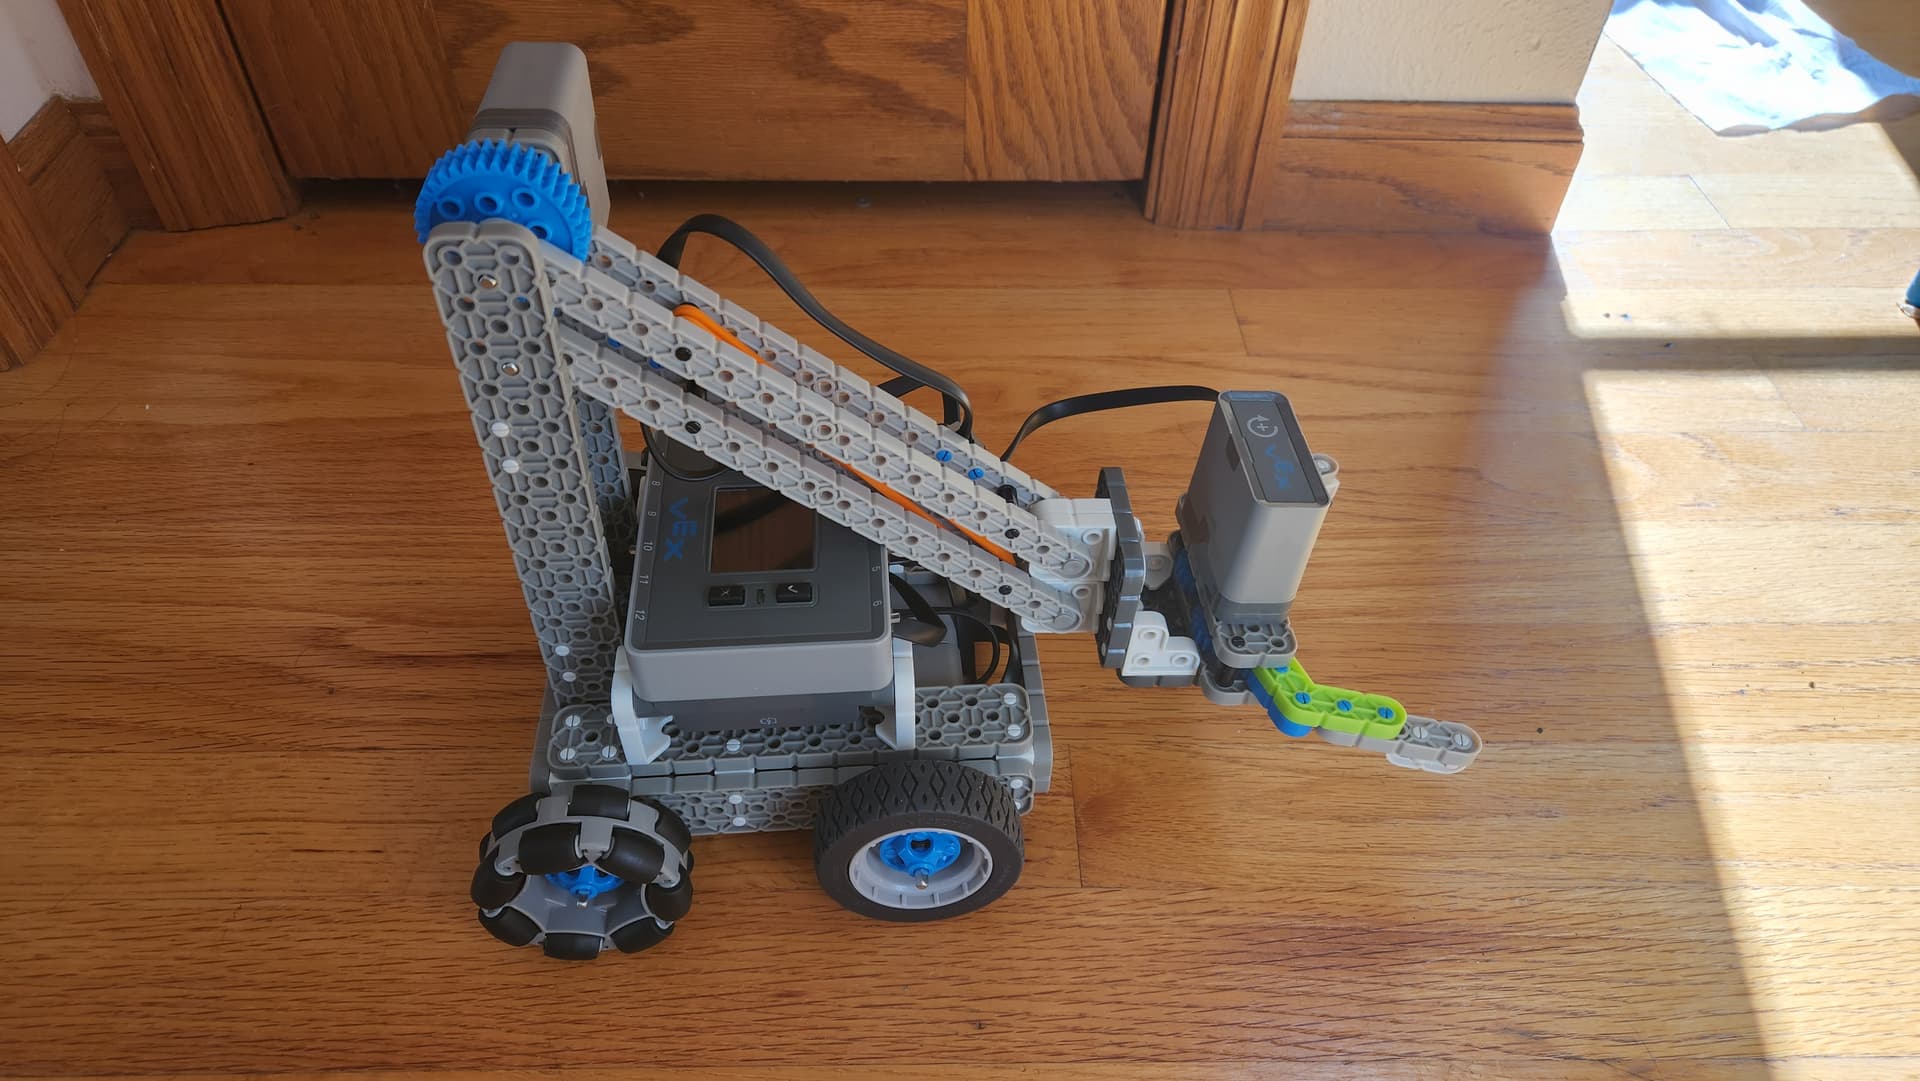
Building a VEX Claw: A Comprehensive Guide
Embarking on a journey to build a VEX claw? You're in the right place! This comprehensive guide will walk you through the process, ensuring you create a robust, functional, and competition-ready claw for your VEX Robotics project. Let's dive in!
Understanding the VEX Claw
Before we begin, let's understand what a VEX claw is and its purpose. A VEX claw is a game piece manipulator used in VEX Robotics competitions. It's designed to pick up, move, and place game pieces like cones and cubes. The claw is typically made of aluminum, with a motor driving a gear train that opens and closes the claw fingers.
Gather Your Materials
Before you start building, ensure you have all the necessary materials. Here's a list to get you started:

- VEX Robotics Claw Kit
- VEX Robotics Brain
- VEX Robotics Motor
- VEX Robotics Batteries
- VEX Robotics Controller
- VEX Robotics Charger
- Tools: Screwdriver, wrench, pliers, etc.
Assembling the Claw Fingers
Start by assembling the claw fingers. The kit comes with two fingers, each consisting of an aluminum frame, a finger plate, and a finger tip. Follow these steps:
- Align the finger plate with the finger tip and insert the finger pin through the holes.
- Slide the finger plate onto the finger frame, ensuring the pin goes through the frame's hole.
- Secure the finger plate to the frame using the provided screws.
Repeat these steps for the second finger.
Attaching the Claw Fingers to the Base
Next, attach the claw fingers to the claw base. The base has two slots for the fingers. Align the fingers with the slots and insert the finger pins into the base's holes. Secure the fingers to the base using the provided screws.
Installing the Motor and Gears
Now, let's install the motor and gears that will drive the claw. The kit comes with a motor, a gear train, and a motor mount. Follow these steps:
- Attach the motor mount to the claw base using the provided screws.
- Insert the motor shaft into the motor mount and secure it with the set screw.
- Align the gear train with the motor shaft and the claw fingers' gear rack.
- Secure the gear train to the motor shaft using the provided set screw.
- Ensure the gear train meshes with the claw fingers' gear rack.
Wiring the Motor
Now that the motor is installed, it's time to wire it to the VEX Robotics Brain. Follow these steps:
- Strip the ends of the motor wires.
- Insert the motor wires into the corresponding ports on the VEX Robotics Brain (usually ports 1 and 2).
- Secure the motor wires to the Brain using cable ties or zip ties.
Programming the Claw
Finally, let's program the claw using the VEXcode software. Here's a simple program to open and close the claw:
| Motor | Speed | Direction |
|---|---|---|
| Motor 1 | 50% | Forward (to open the claw) |
| Motor 1 | 50% | Reverse (to close the claw) |
You can adjust the speed and direction as needed for your specific application.
Testing Your VEX Claw
Congratulations! You've built your VEX claw. Now it's time to test it. Connect your VEX Robotics Controller to the Brain, turn on the Brain and the controller, and test the claw's opening and closing functions. Make any necessary adjustments to ensure optimal performance.
Remember, building and programming a VEX claw is a learning process. Don't be discouraged if it doesn't work perfectly on your first try. Keep practicing, keep learning, and you'll soon have a competition-ready claw!