Programmable Locking Cells (PLC) for Modular Robots with High Stiffness ...
Such systems offer structure-level adaptability well suited for dynamic environments. However, most modular platforms focus on topological transformation and largely overlook localized stiffness programmability—an essential capability for robots to interact stably with physical environments and execute high -force tasks.

A novel dual-arm control framework (ACCF), which considers a fast estimation of the gravity variation and active anti-overturning response, offers a practical and easy-to-use approach for achieving variable loads or loose objects carrying.

This particular example perfectly highlights why High Adaptability Tying Strategies For Variable Weight Loads is so captivating.
Introduction With physical training, the internal load is understood as the physiological responses resulting from the body's exposure to a given external load (Halson, 2014 ). In strength training, the external load comprises all the acute and chronic variables that can be manipulated in a session or in a training program, for example, resistance load ( weight lifted), number of repetitions ...
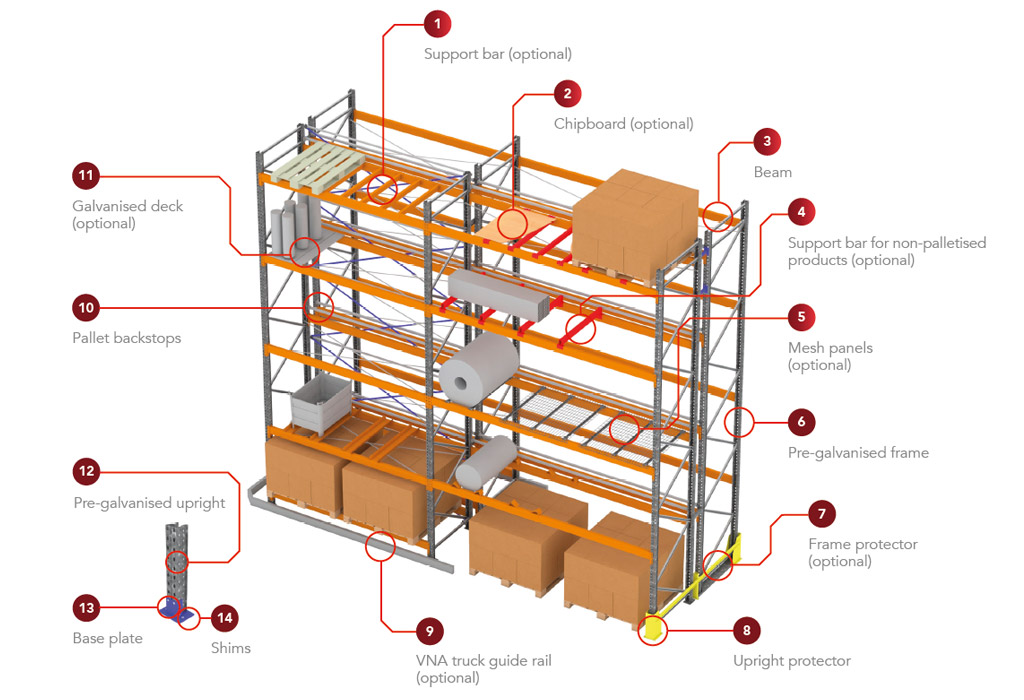
Additional Notes on High Adaptability Tying Strategies For Variable Weight Loads
Figure 10 from An Underactuated Tendon-Driven Gripper with Variable. It gives the article a little more context before the image collection begins.
HAARN: A Deep Neural Network-Based Intelligent Control Method for High. This note connects the source idea with the visuals in a simple, reader-friendly way.
The six accepted design strategies that enhance adaptability in. This note connects the source idea with the visuals in a simple, reader-friendly way.
Looking at multiple sources also helps separate the main idea from small decorative details.
These notes are added so the page offers more than images and gives each visitor a clearer reason to keep reading.