Overview of Sensor Based Motion Planning For Path Tracking And Obstacle

Then the turning radius for avoiding an obstacle , which is inversely proportional to the virtual force, is calculated. By integrating the geometric path tracking method and the sensor-based obstacle avoidance method, the vehicle follows the waypoints and avoids unexpected obstacles while it considers the motion constraints.
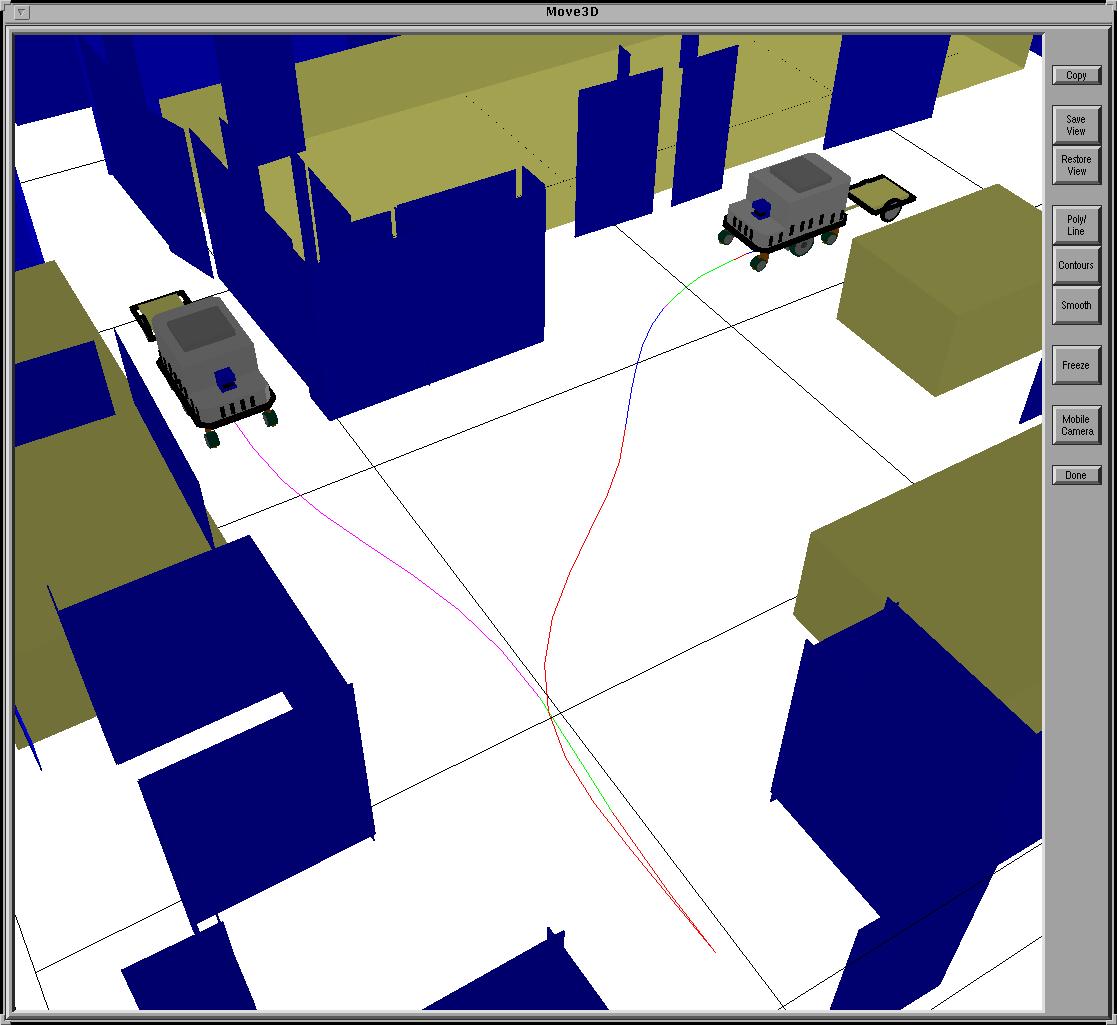
A sensor-based motion planning method for ro botic vehicles with nonholonomic constraints that follows the waypoints and avoids unexpected obstacles while it considers the motion constraints.
Key Details About Sensor Based Motion Planning For Path Tracking And Obstacle

This article discusses a motion planning method for robotic vehicles facing nonholonomic constraints. It integrates geometric path tracking and obstacle avoidance techniques, ensuring vehicles can navigate waypoints while avoiding obstacles . The proposed method is validated through simulations, demonstrating effective navigation and adherence to motion constraints.
The sensor-based system is utilized an unknown or changing environment, to perform real-time obstacle avoidance and real-time path planning functions. The sensing elements that are most commonly found in the literature include infrared and ultrasound, CCD camera or CMOS image sensors , laser light pens, global positioning systems (GPS), etc. [1].

Robot path planning and obstacle avoidance algorithm based ...
Zheng K (2024) Autonomous obstacle avoidance and trajectory planning for mobile robot based on dual-loop trajectory tracking control and improved artificial potential field method. In: Actuators 13 (1):37. MDPI Hoshino S, Kubota Y, Yoshida Y (2024) Motion planner based on CNN with LSTM through mediated perception for obstacle avoidance.
In contrast, local path planning involves navigating a robot in dynamic or unknown environments where the algorithm adapts to real-time obstacles and changes. This method primarily focuses on real-time obstacle avoidance using sensor-based data for safe navigation [3].
Trajectory tracking and obstacle avoidance in dynamic environments ...
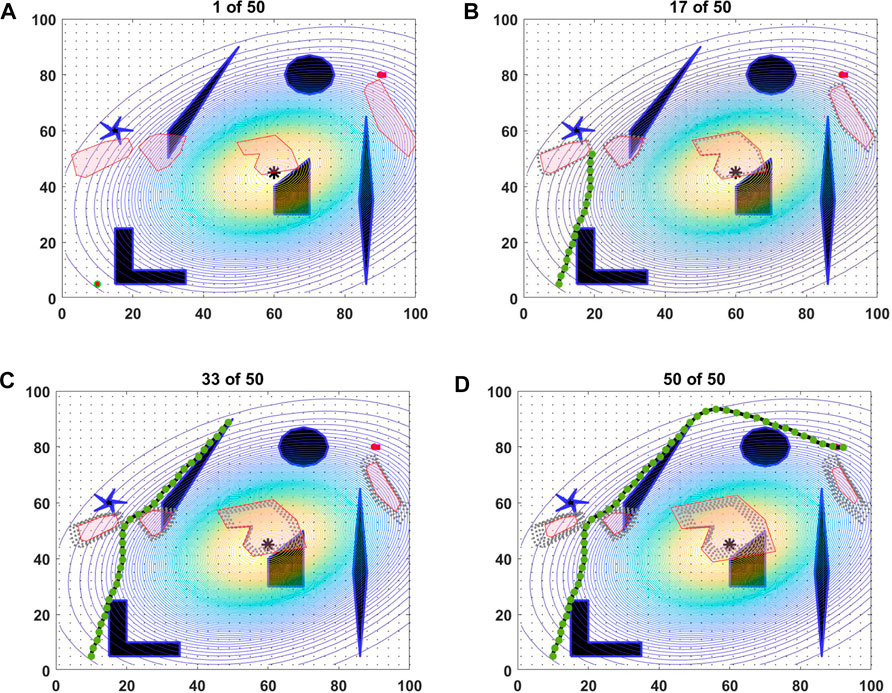
Ensuring that a robot employing demonstration learning models can simultaneously achieve accurate trajectory tracking of demonstrated paths and effective avoidance of moving obstacles in dynamic environments remains a critical research challenge. This paper proposes a real-time trajectory planning framework based on an enhanced artificial potential field (APF) approach to address this dual ...
This paper proposes an integrated framework combining a risk potential field and dual-layer model predictive control (MPC) for autonomous obstacle avoidance path planning and tracking . First, environmental risks are modeled through potential fields representing road boundaries, target attractions, and obstacle repulsions.

Path planning techniques for mobile robots
In the local path planning , we introduce the sensors commonly used in the detection environment, including laser radar and visual sensor . Next, according to the characteristics of algorithms, mobile robot path planning algorithms are divided into three categories: classical algorithms, bionic algorithms and artificial intelligence algorithms.

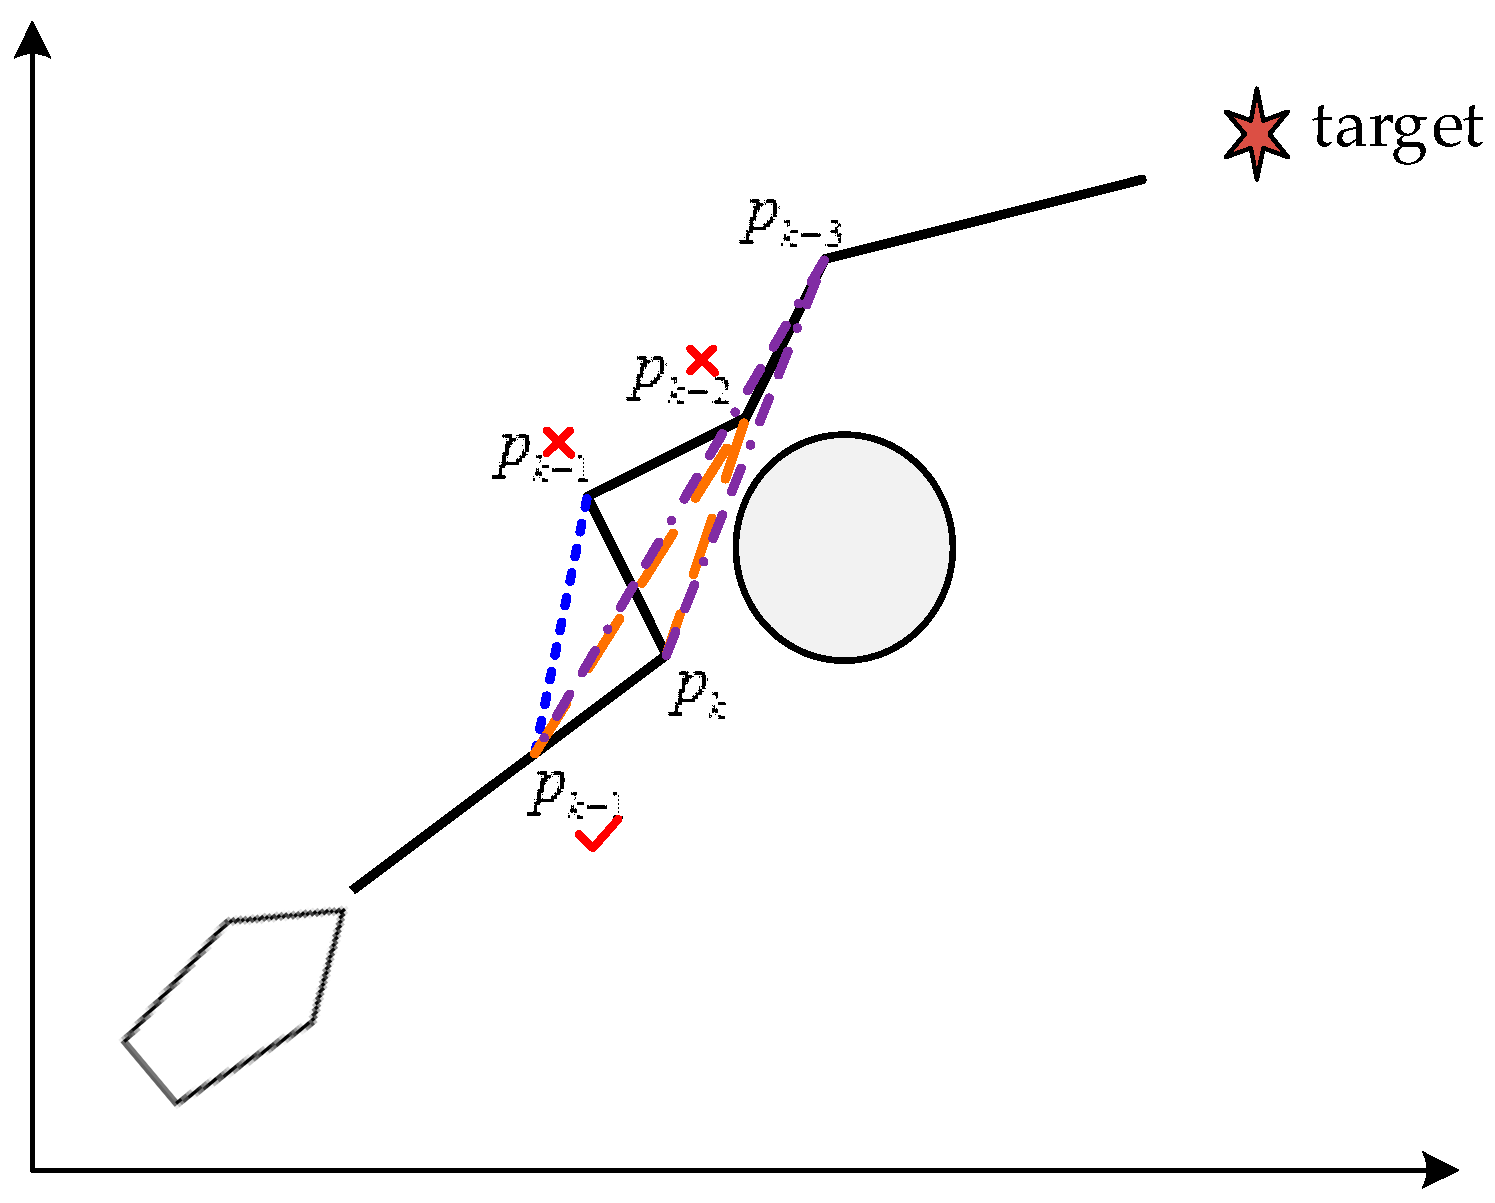


To address this limitation, we introduce SPOT (Sensing-augmented Planning via Obstacle Threat modeling), a unified planning framework for observation-aware trajectory planning that explicitly incorporates sensing objectives into motion optimization.