Electronic Circuits and Projects
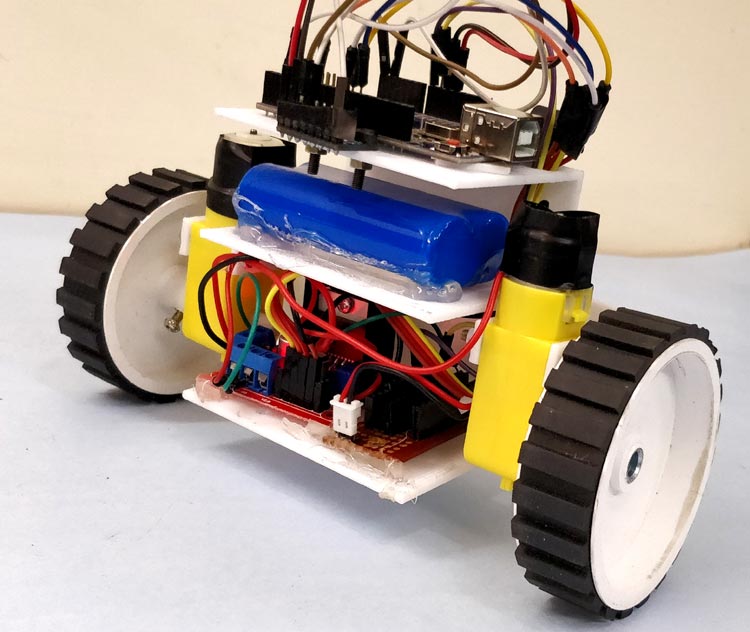
After being inspired by RYNO motors and other self balancing scooters from Segway, I always wanted to build something similar. Thinking for while, I decided to build a S elf Balancing Robot using Arduino . This way I would be able to grasp the underlying concept behind all these scooters and also learn how PID algorithm works.

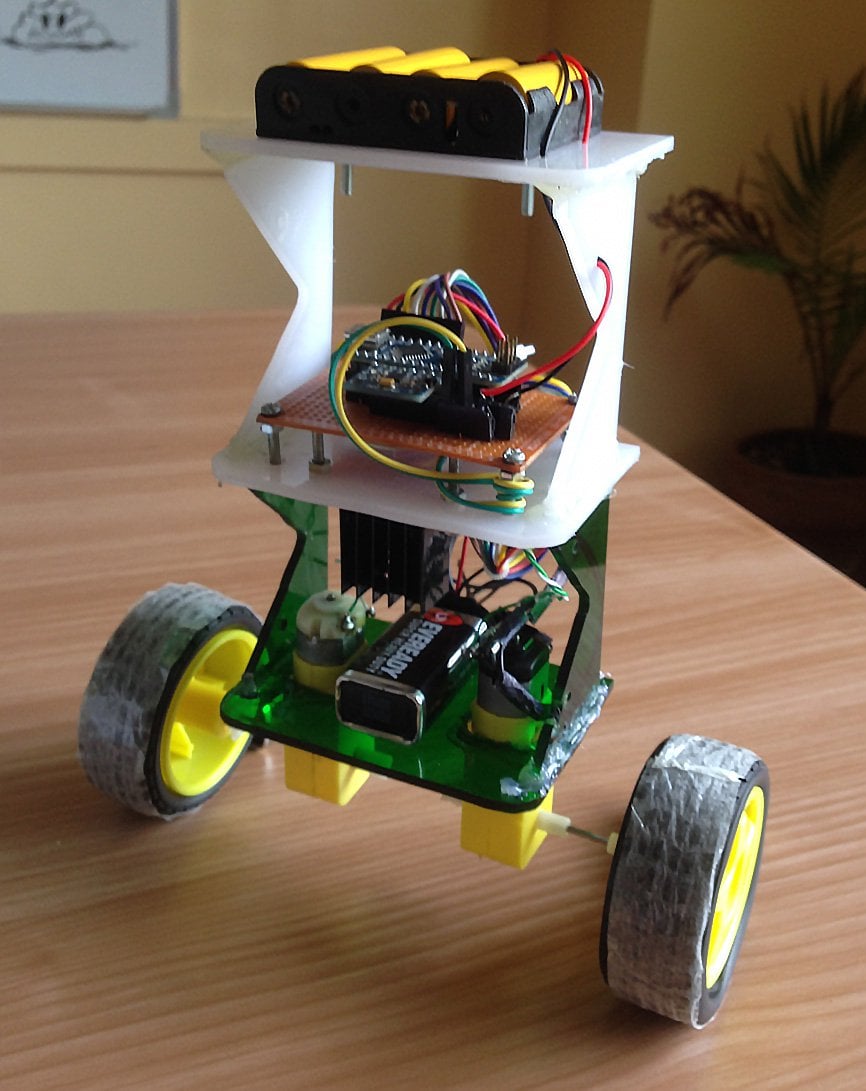
Arduino Self-Balancing Robot: Hello, everyone! In this instructable, I'll show you how to build a small self-balancing robot that can move around avoiding obstacles. This is a tiny robot measuring 4 inches wide and 4 inches tall and is based on the Arduino Pro Mini development …
DIY Self Balancing Robot using Arduino

The self balancing robot circuit diagram above shows the whole connections between Arduino Uno, MPU6050 sensor, and L298N motor driver to build a self balancing robot.
Create your own self-balancing robot using Arduino ! Follow this beginner's tutorial to learn about sensors, motors, and balance control step by step.

DIY Self Balancing Robot with Arduino and MPU6050
The Arduino Self Balancing Robot is a fantastic project that combines electronics , programming, and control theory. By using the MPU6050 sensor and PID algorithm, the robot can dynamically correct its position and remain upright on two wheels.
A self-balancing robot built with Arduino is a captivating project that combines mechanical engineering, electronics , and programming skills. By integrating sensors and motors with an Arduino board, this project aims to create a robot that can maintain its balance on two wheels.

Arduino Self
The document describes the design and functionality of a self-balancing robot using an Arduino Nano, which maintains its upright position through a PID control algorithm and feedback from a gyroscopic sensor. It details the components used, working principles, circuit diagrams, and programming flow, as well as challenges faced and potential future enhancements. The project showcases the ...
This document provides an overview of creating a self-balancing robot. It discusses using an Arduino microcontroller along with sensors like an accelerometer and gyroscope to measure the robot's pitch and control motors to balance. It describes the inverted pendulum physics model and potential control algorithms using sensors individually or combined. Equations are provided for the robot's ...

Arduino two weel self Balancing Robot
Arduino two weel self Balancing Robot This is a relatively simple, visually effective balancing robot project that only requires four components to make. Detailed video, instructions, schematic, and code at: Mar 6, 2025 • 147612 views • 31 respects •