Adaptive Locomotion Learning for Quadruped Robots by Combining DRL with ...
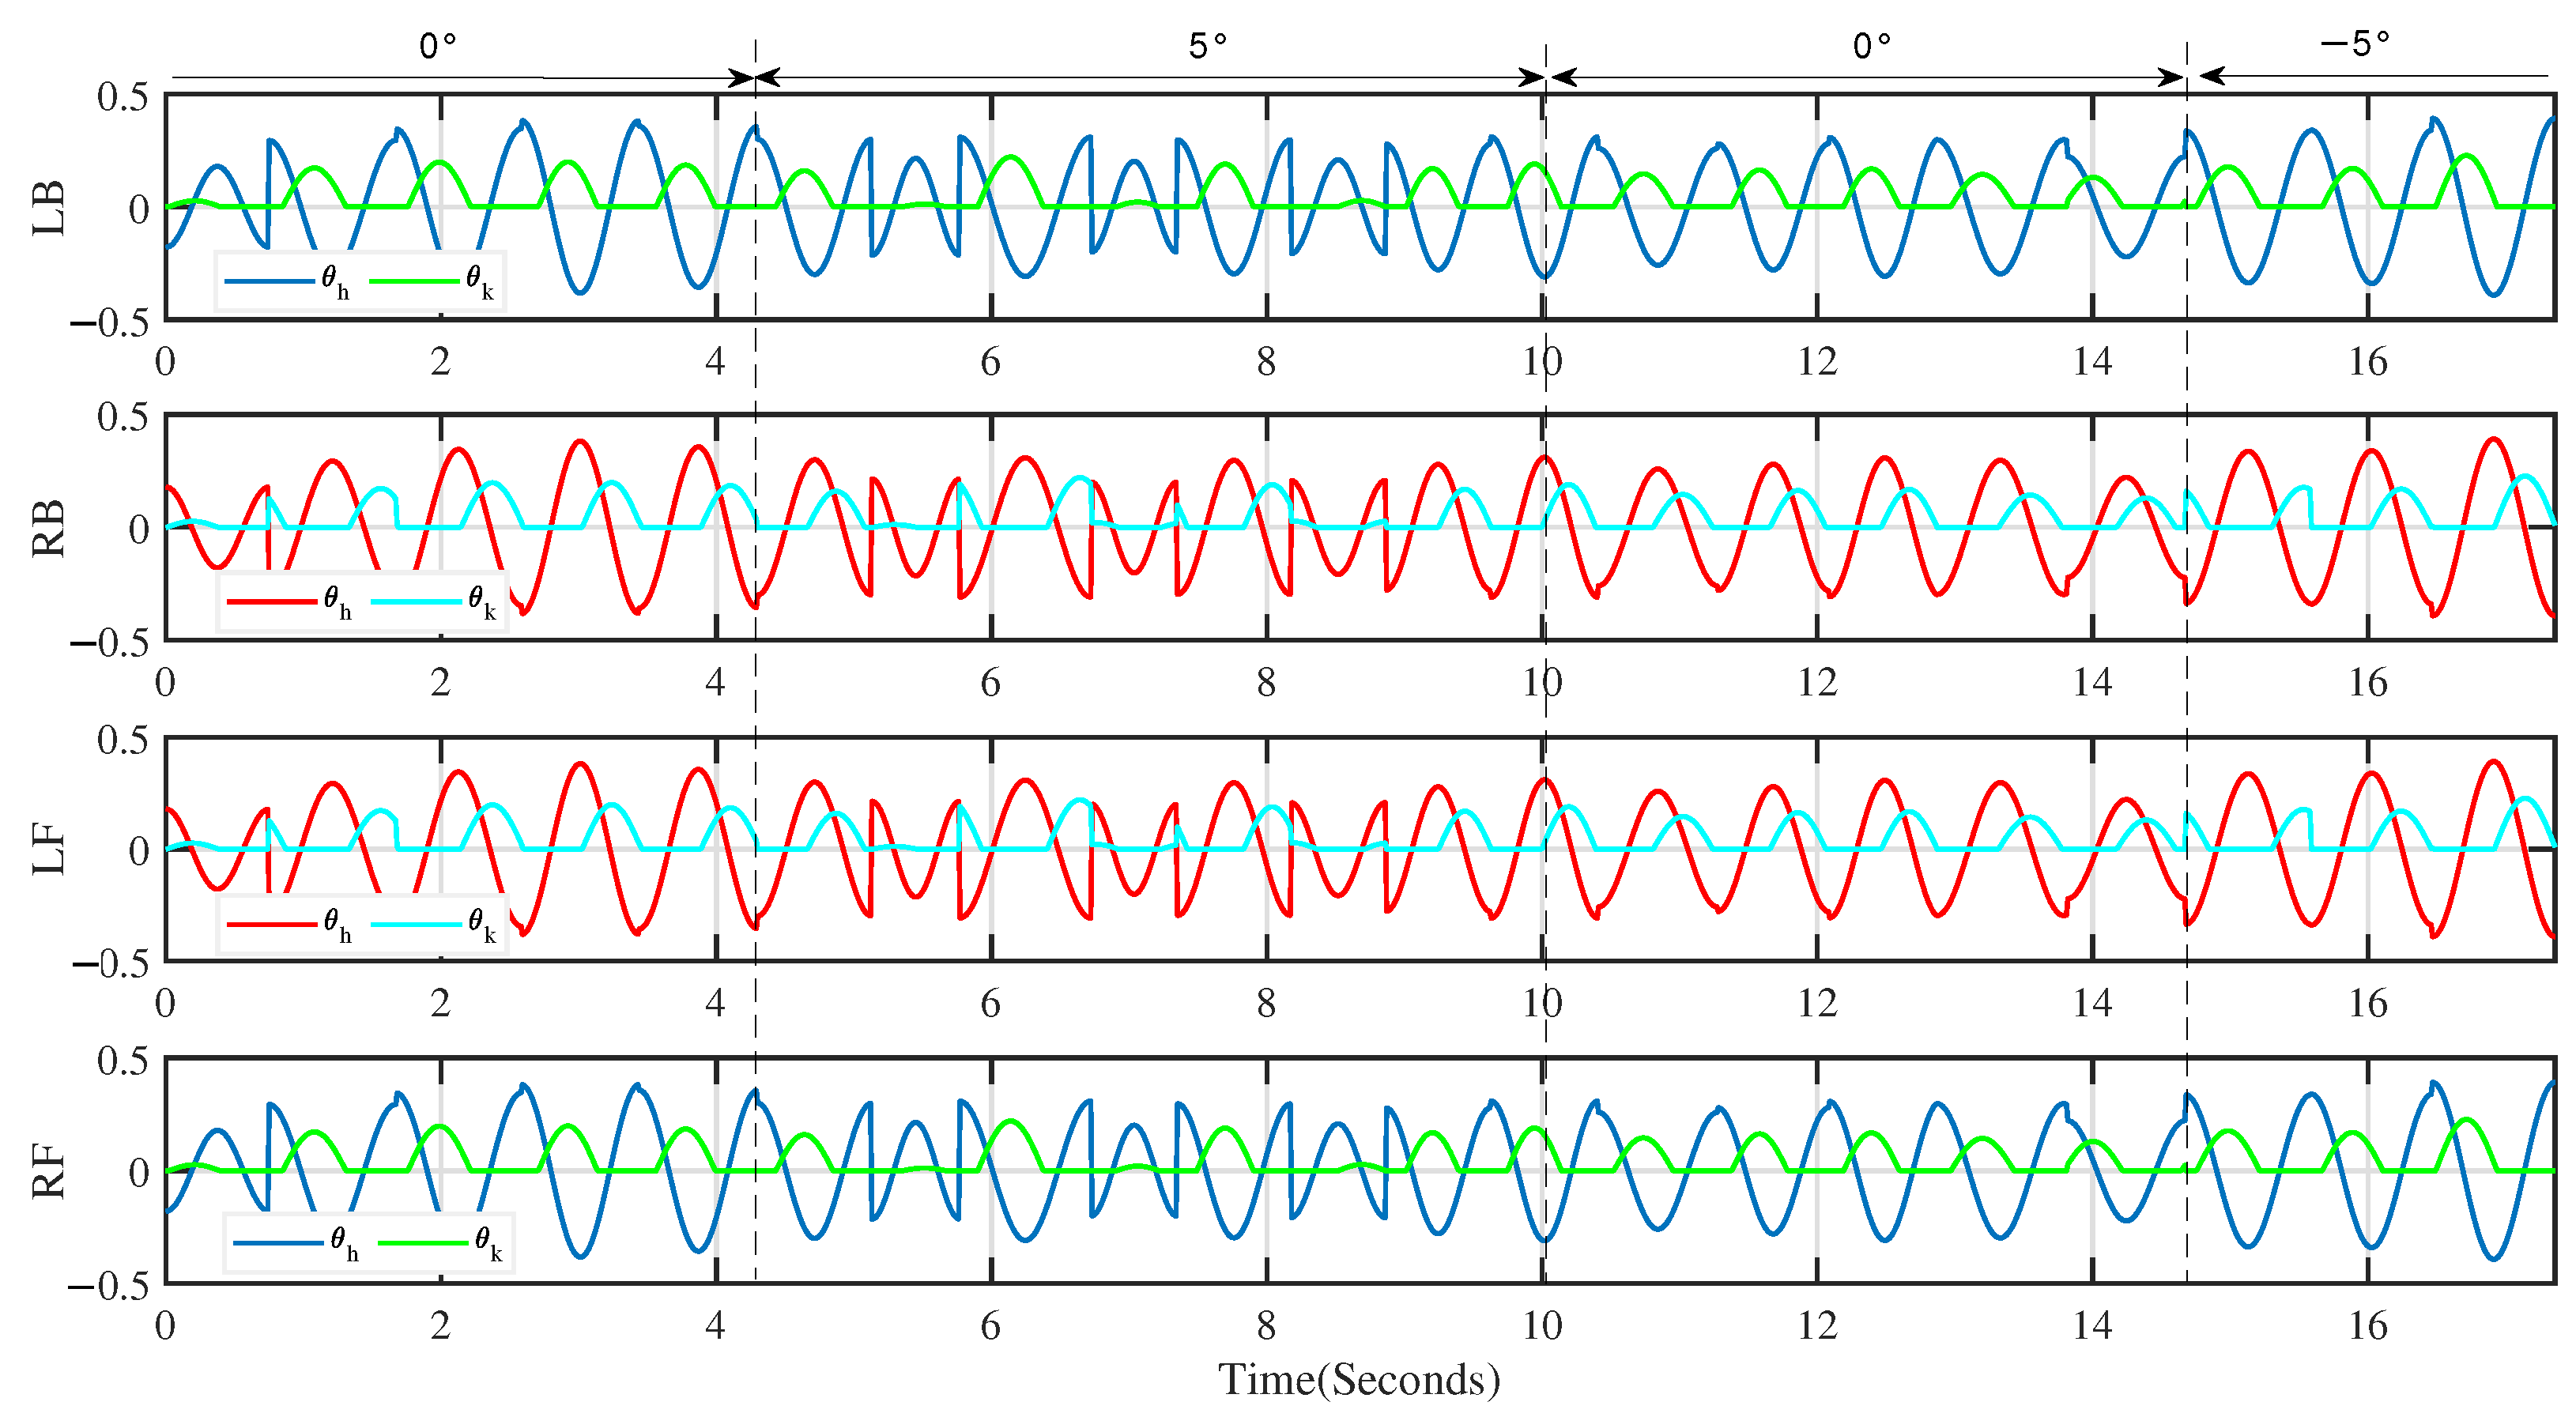
Animals have evolved to adapt to complex and uncertain environments, acquiring locomotion skills for diverse surroundings. To endow a robot's animal-like locomotion ability, in this paper, we propose a learning algorithm for quadruped robots based on deep reinforcement learning ( DRL ) and a rhythm controller that is based on a cosine oscillator. For a quadruped robot , two cosine oscillators ...

To endow a robot's animal-like locomotion ability, in this paper, we propose a learning algorithm for quadruped robots based on deep reinforcement learning ( DRL ) and a rhythm controller that is ...
Adaptive Locomotion Learning for Quadruped Robots by Combining DRL with ...

Animals have evolved to adapt to complex and uncertain environments, acquiring locomotion skills for diverse surroundings. To endow a robot's animal-like locomotion ability, in this paper, we propose a learning algorithm for quadruped robots based on deep reinforcement learning ( DRL ) and a rhythm controller that is based on a cosine oscillator.
To endow a robot's animal-like locomotion ability, in this paper, we propose a learning algorithm for quadruped robots based on deep reinforcement learning ( DRL ) and a rhythm controller that is based on a cosine oscillator.

Adaptive Locomotion Learning for Quadruped Robots by Combining DRL with ...
Mentioning: 1 - Animals have evolved to adapt to complex and uncertain environments, acquiring locomotion skills for diverse surroundings. To endow a robot's animal-like locomotion ability, in this paper, we propose a learning algorithm for quadruped robots based on deep reinforcement learning ( DRL ) and a rhythm controller that is based on a cosine oscillator. For a quadruped robot , two ...
作者: Xiaoping Zhang, Yitong Wu, Huijiang Wang, Fumiya Iida, Li Wang · 单位: Department of Engineering, University of Cambridge, Cambridge CB2 PZ, UK, School of Electrical and Control Engineering, North China University of Technology, Beijing 100144, China, North China University of Technology, University of Cambridge · 会议/期刊: Applied Sciences · 方向: 2023 · 发布 ...

Overview of Adaptive Locomotion Learning For Quadruped Robots By Combining Drl
This project explores the application of reinforcement learning for developing agile and adaptive locomotion in quadruped robots . By employing deep reinforcement learning ( DRL ) techniques, including Proximal Policy Optimization (PPO), and PyBullet simulation framework we trained policies to execute high-speed gaits like galloping and trotting, as well as navigate to specified targets. A hybrid ...
We introduce a DRL -based motion planning system for quadrupedal (four legged) robots that learns stable locomotion in unstructured terrain through curriculum learning .

Agile perceptive multiskill locomotion for quadrupedal robots in the ...
Quadrupedal animals naturally adapt their gaits and motor skills to their physiology, environment, terrain, and locomotion speed (1, 2). This adaptive behavior includes approaching obstacles through fast running and jumping and combining various motor skills into precisely timed and coordinated sequences. Consequently, quadrupeds agilely traverse complex terrains by using multiple locomotion ...




Animals have evolved to adapt to complex and uncertain environments, acquiring locomotion skills for diverse surroundings. To endow a robot's animal-like locomotion ability, in this paper, we propose a learning algorithm <b>for ...