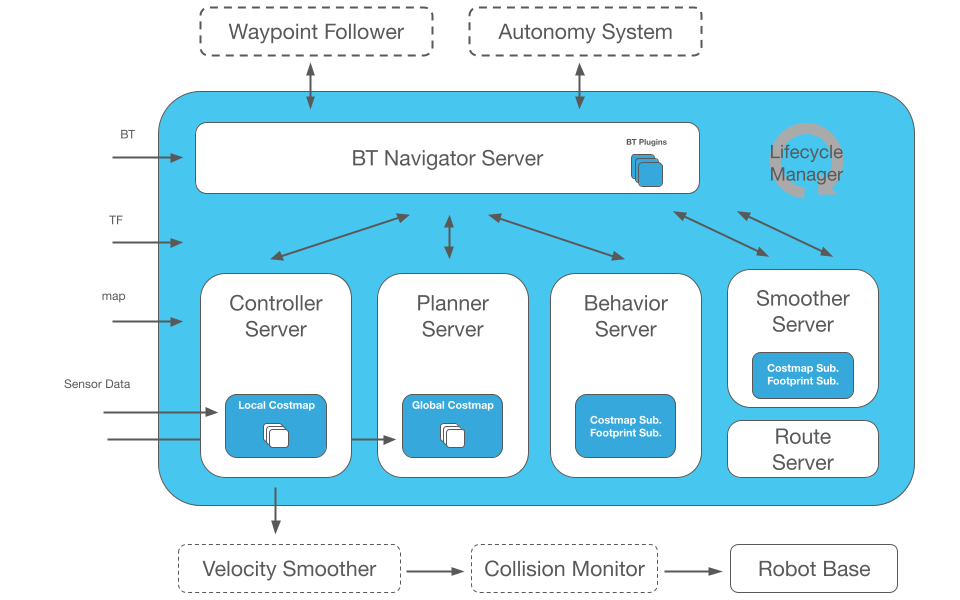
Understanding real
We are designing and prototyping ROS 2 with real-time performance constraints in mind, since this is a requirement that was not considered in the early stages of ROS 1 and it is now intractable to refactor ROS 1 to be real-time friendly. This document outlines the requirements of real-time computing and best practices for software engineers.
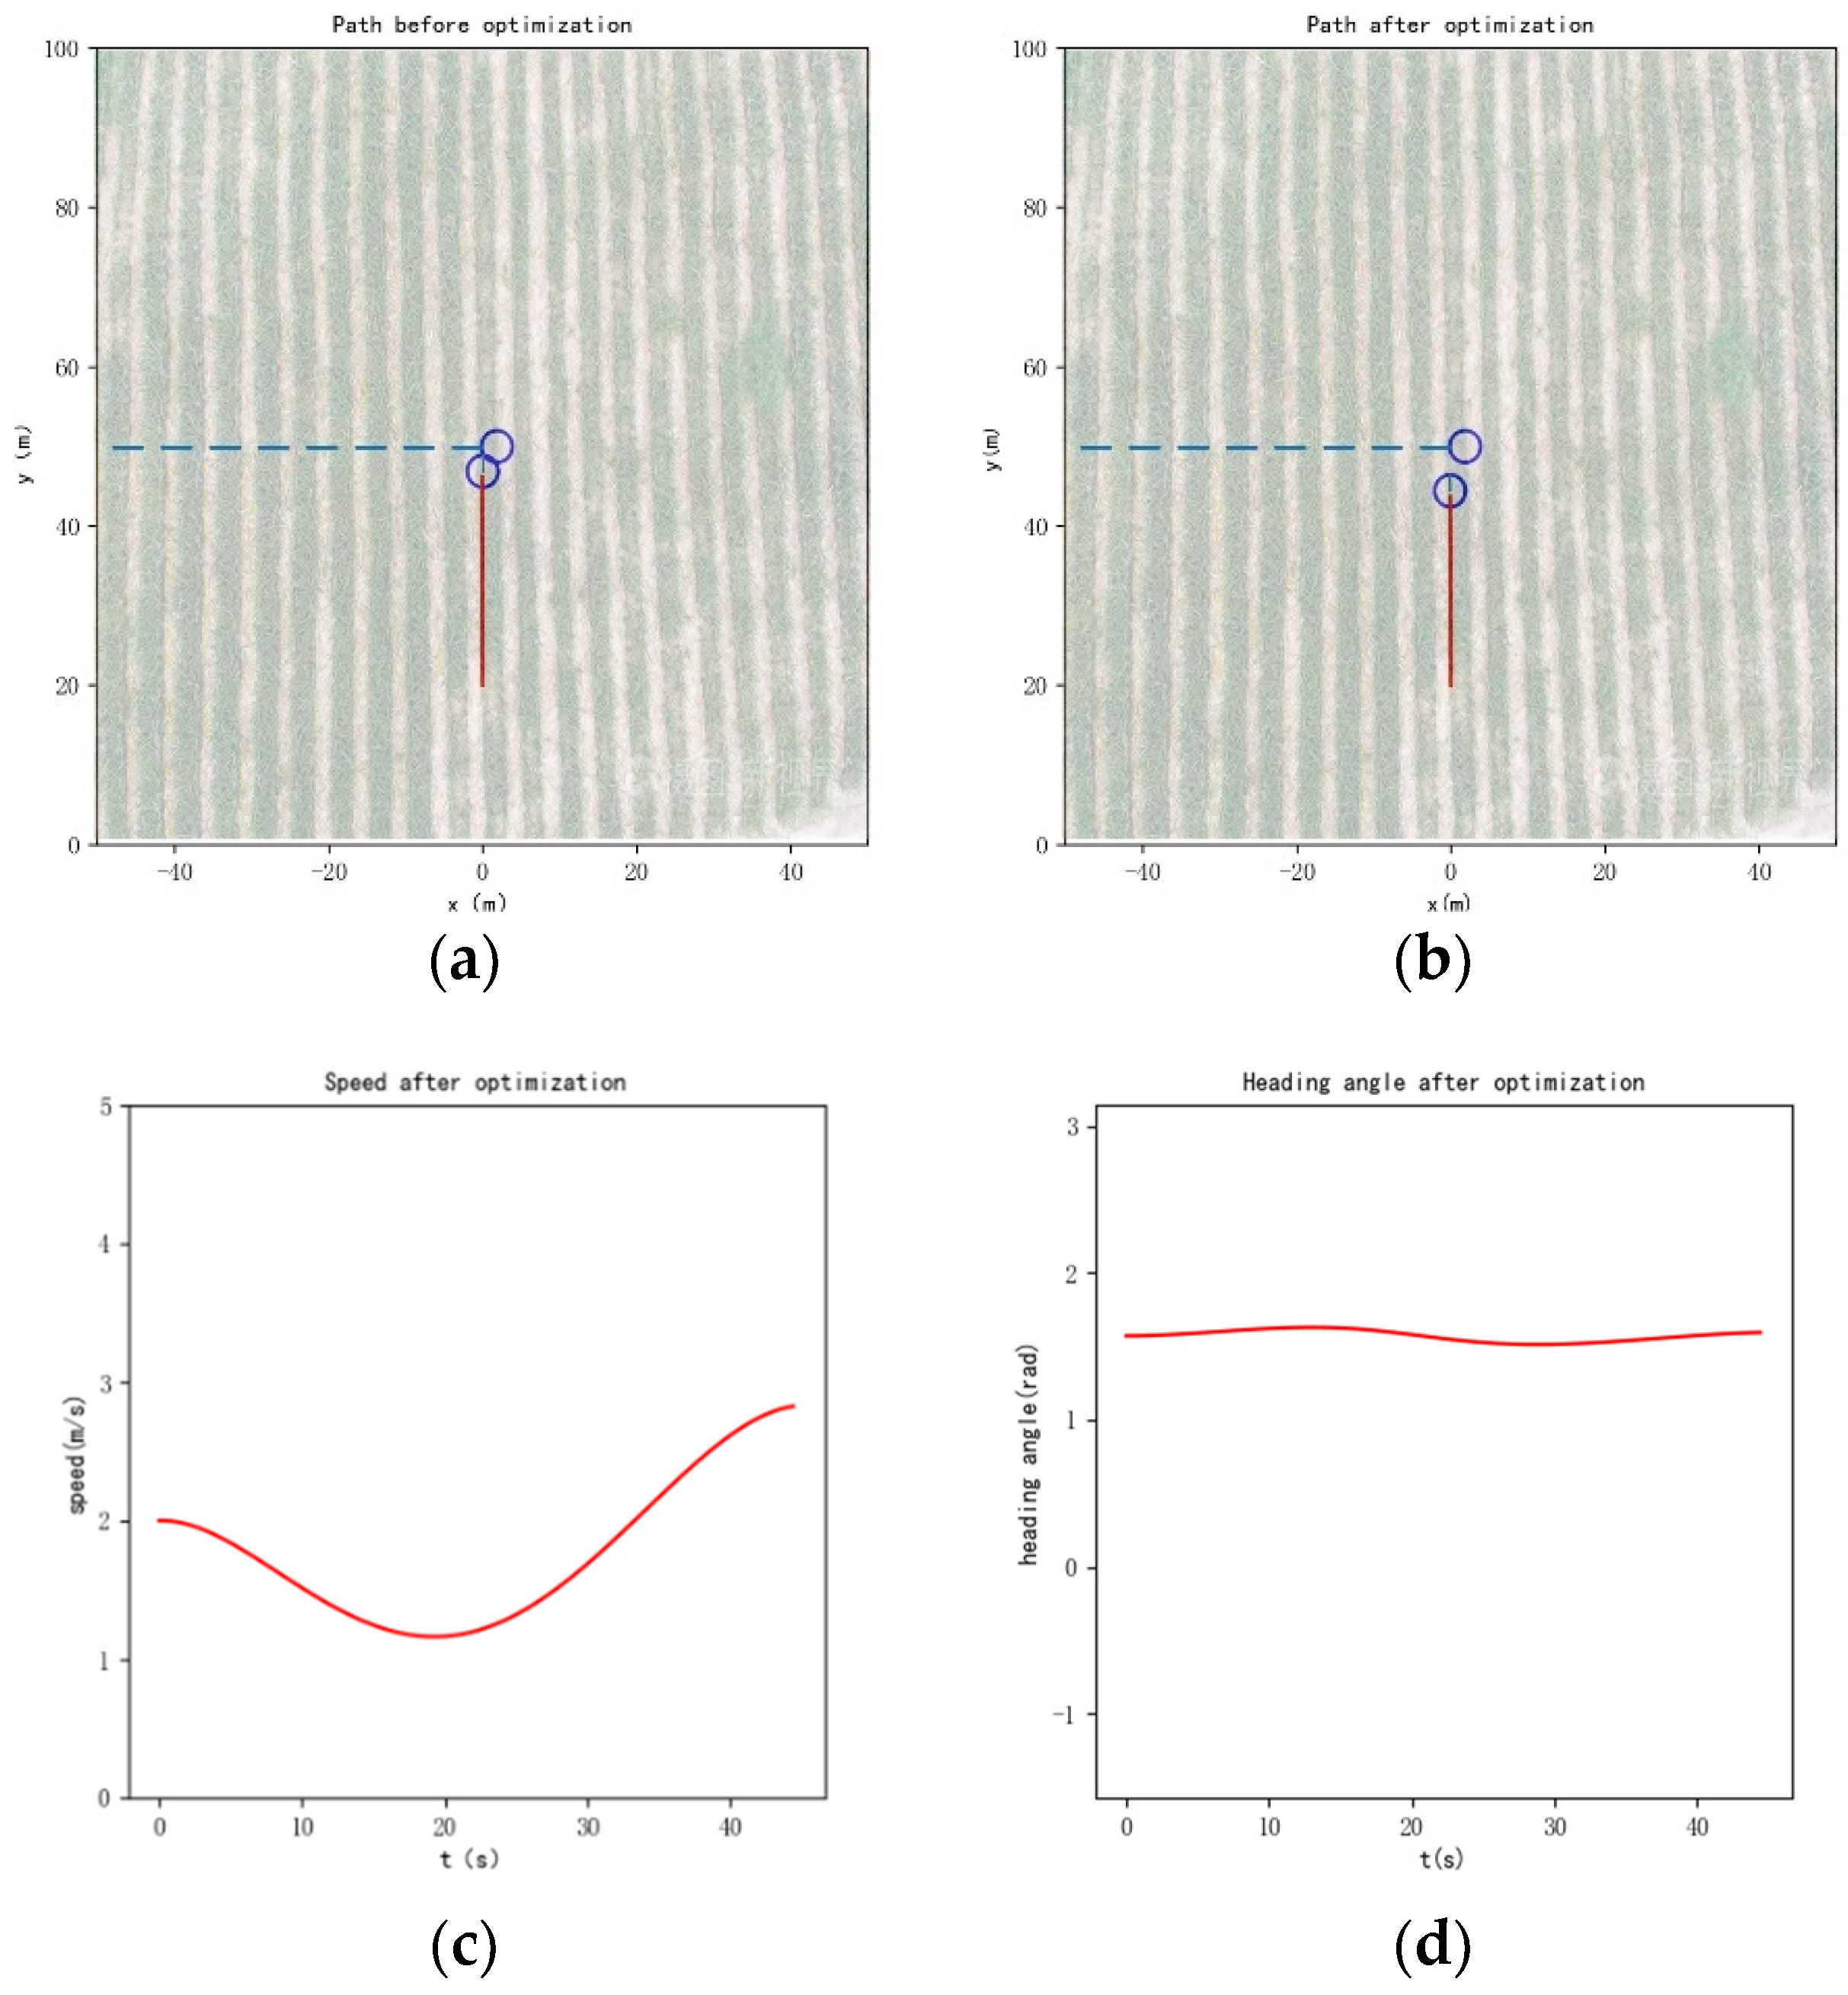
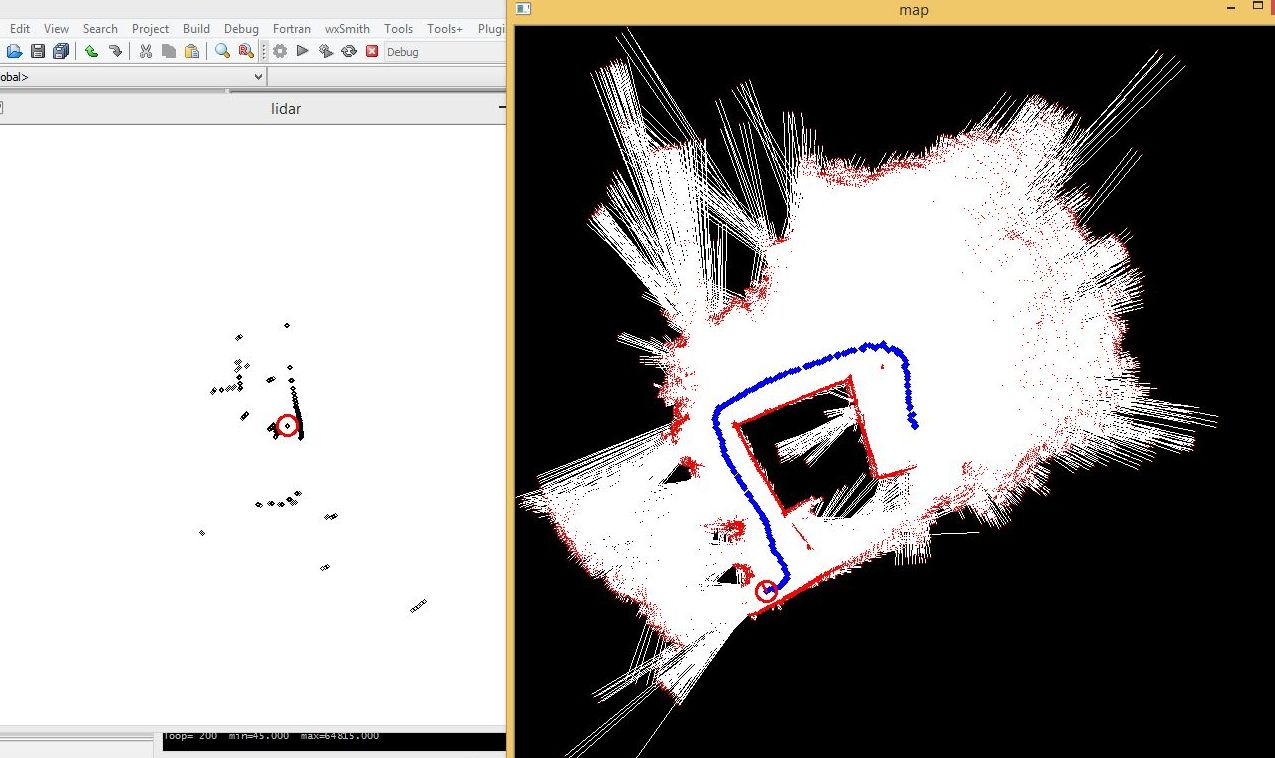
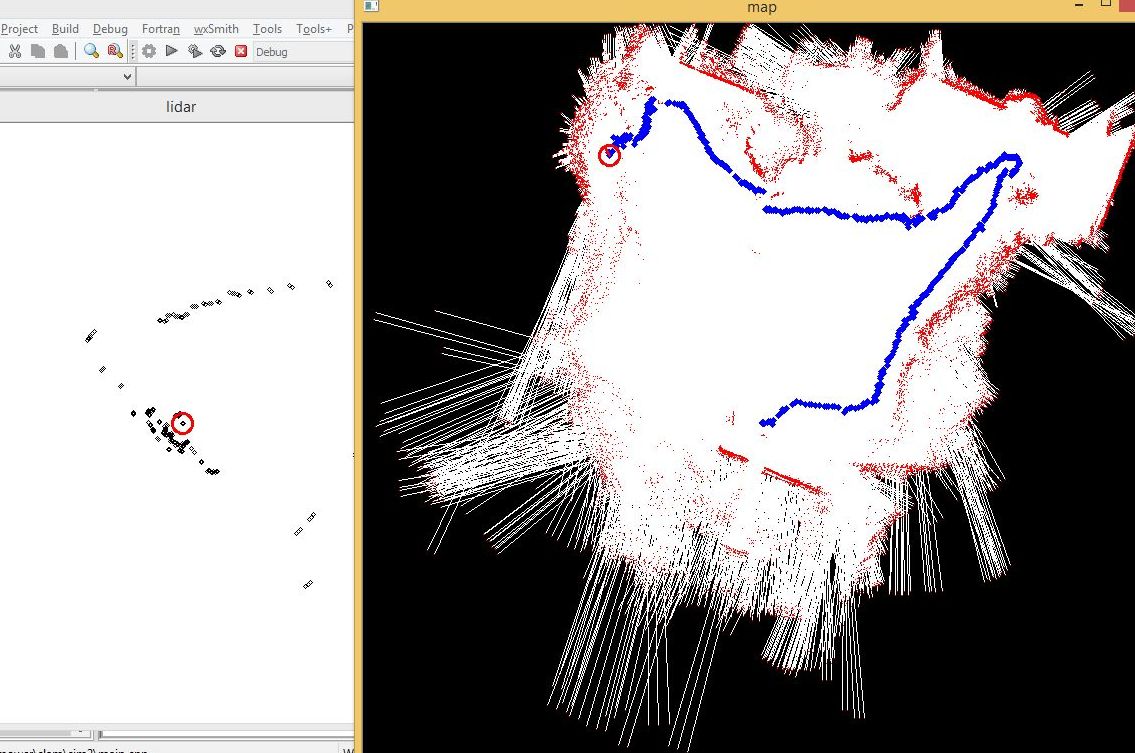
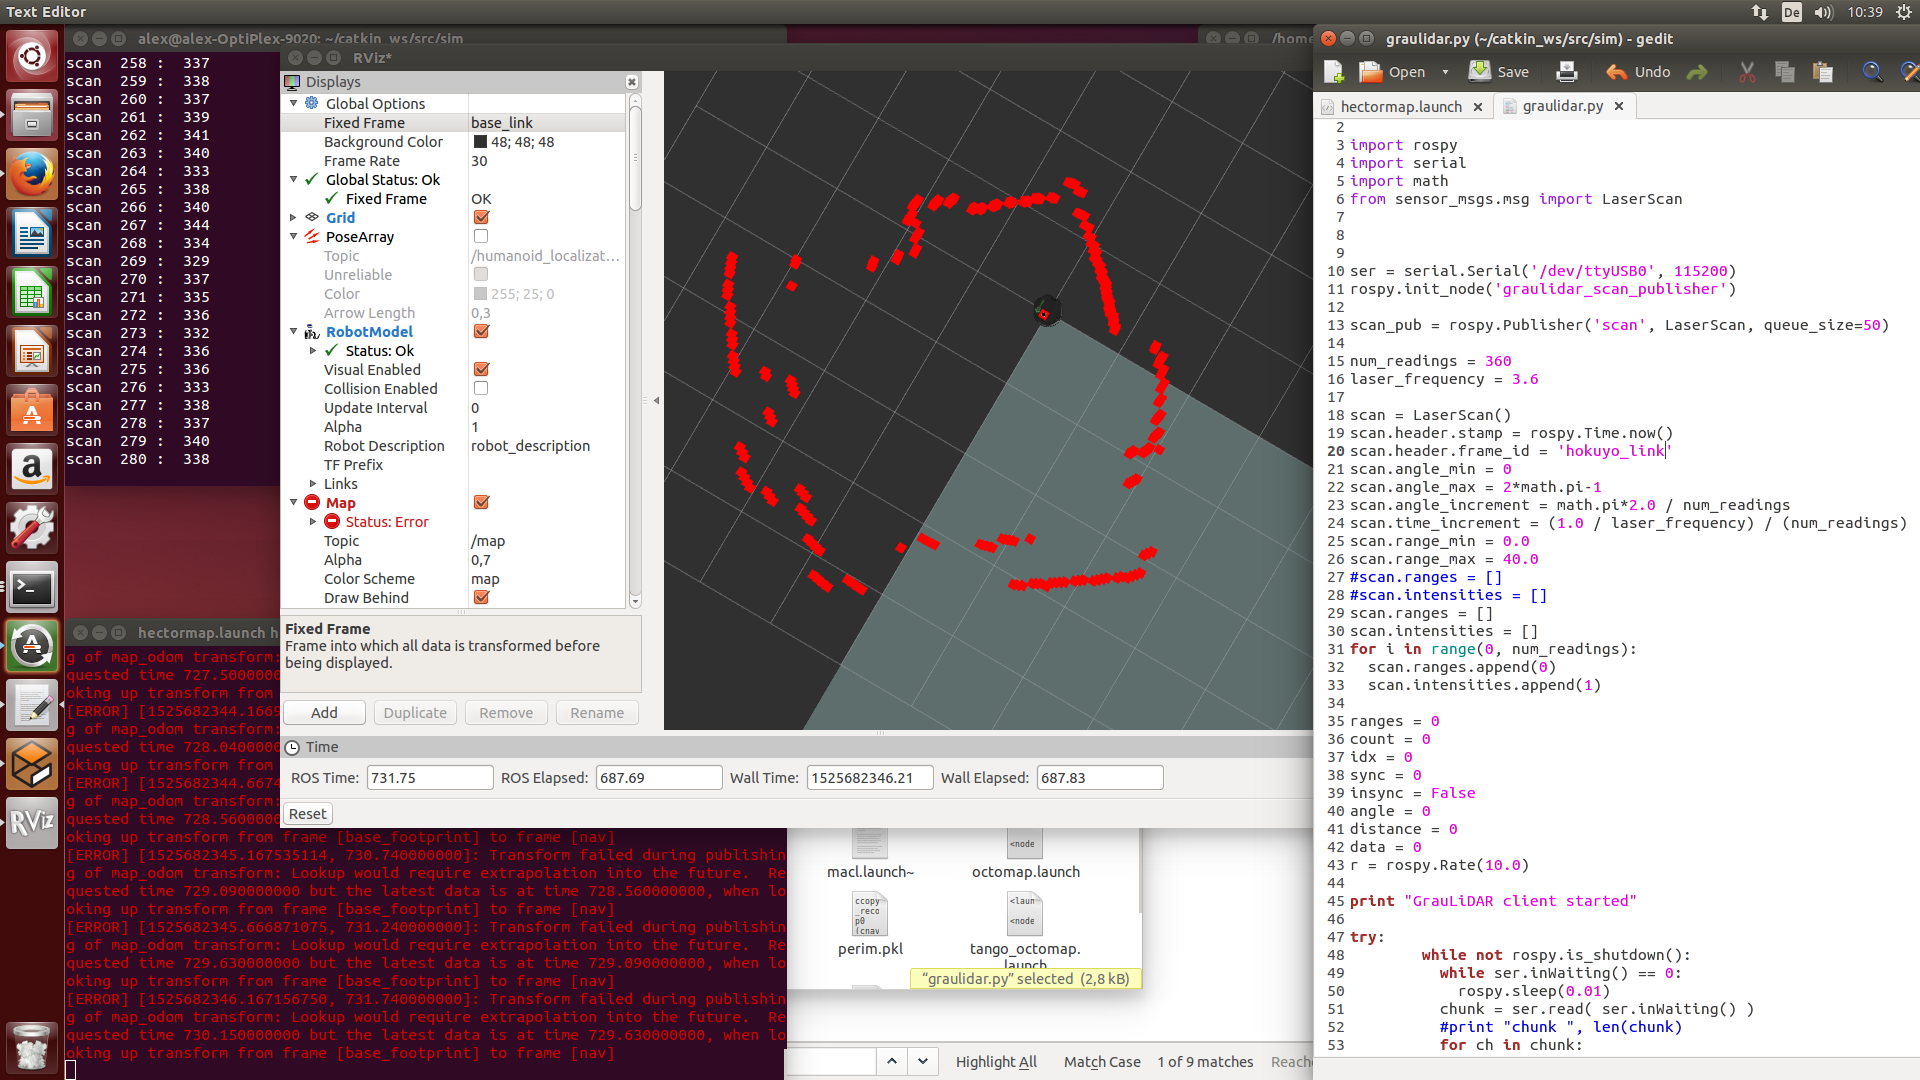
This paper addresses these gaps by introducing a five-layer DT framework integrated with Unity3D and ROS that supports real-time bidirectional control through optimised A* path planning based on real-time LiDAR information.

This particular example perfectly highlights why Real Time Path Constraint Updates In Ros is so captivating.
PDF Priority
Although ROS 2, the new version of ROS , aims to better support real-time capabilities by employing a new software architecture and the Data Distri-bution Service (DDS), it still remains challenging to guarantee stringent timing constraints in ROS -based systems.
5.3.5.4. Understanding real
We are designing and prototyping ROS 2 with real-time performance constraints in mind, since this is a requirement that was not considered in the early stages of ROS 1 and it is now intractable to refactor ROS 1 to be real-time friendly. This document outlines the requirements of real-time computing and best practices for software engineers.
Understanding Real Time Path Constraint Updates In Ros Before the Gallery
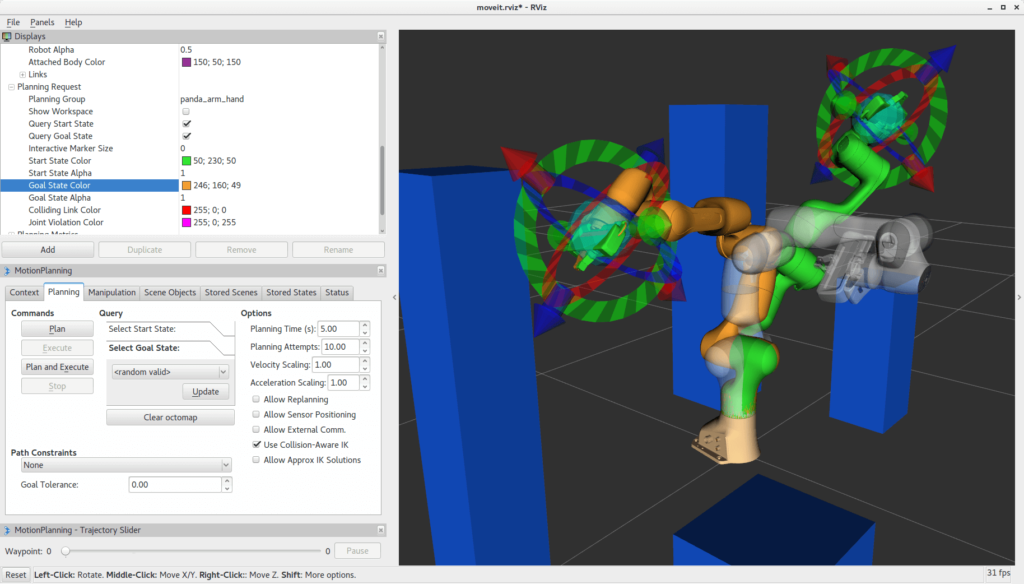
MoveIt 2 enables realtime robot arm control with ROS 2. For Real Time Path Constraint Updates In Ros, this point helps readers notice the most relevant visual details before moving into the gallery.
Husarion CORE2 - New ROS Tutorials are Here | Crowd Supply. This note connects the source idea with the visuals in a simple, reader-friendly way.
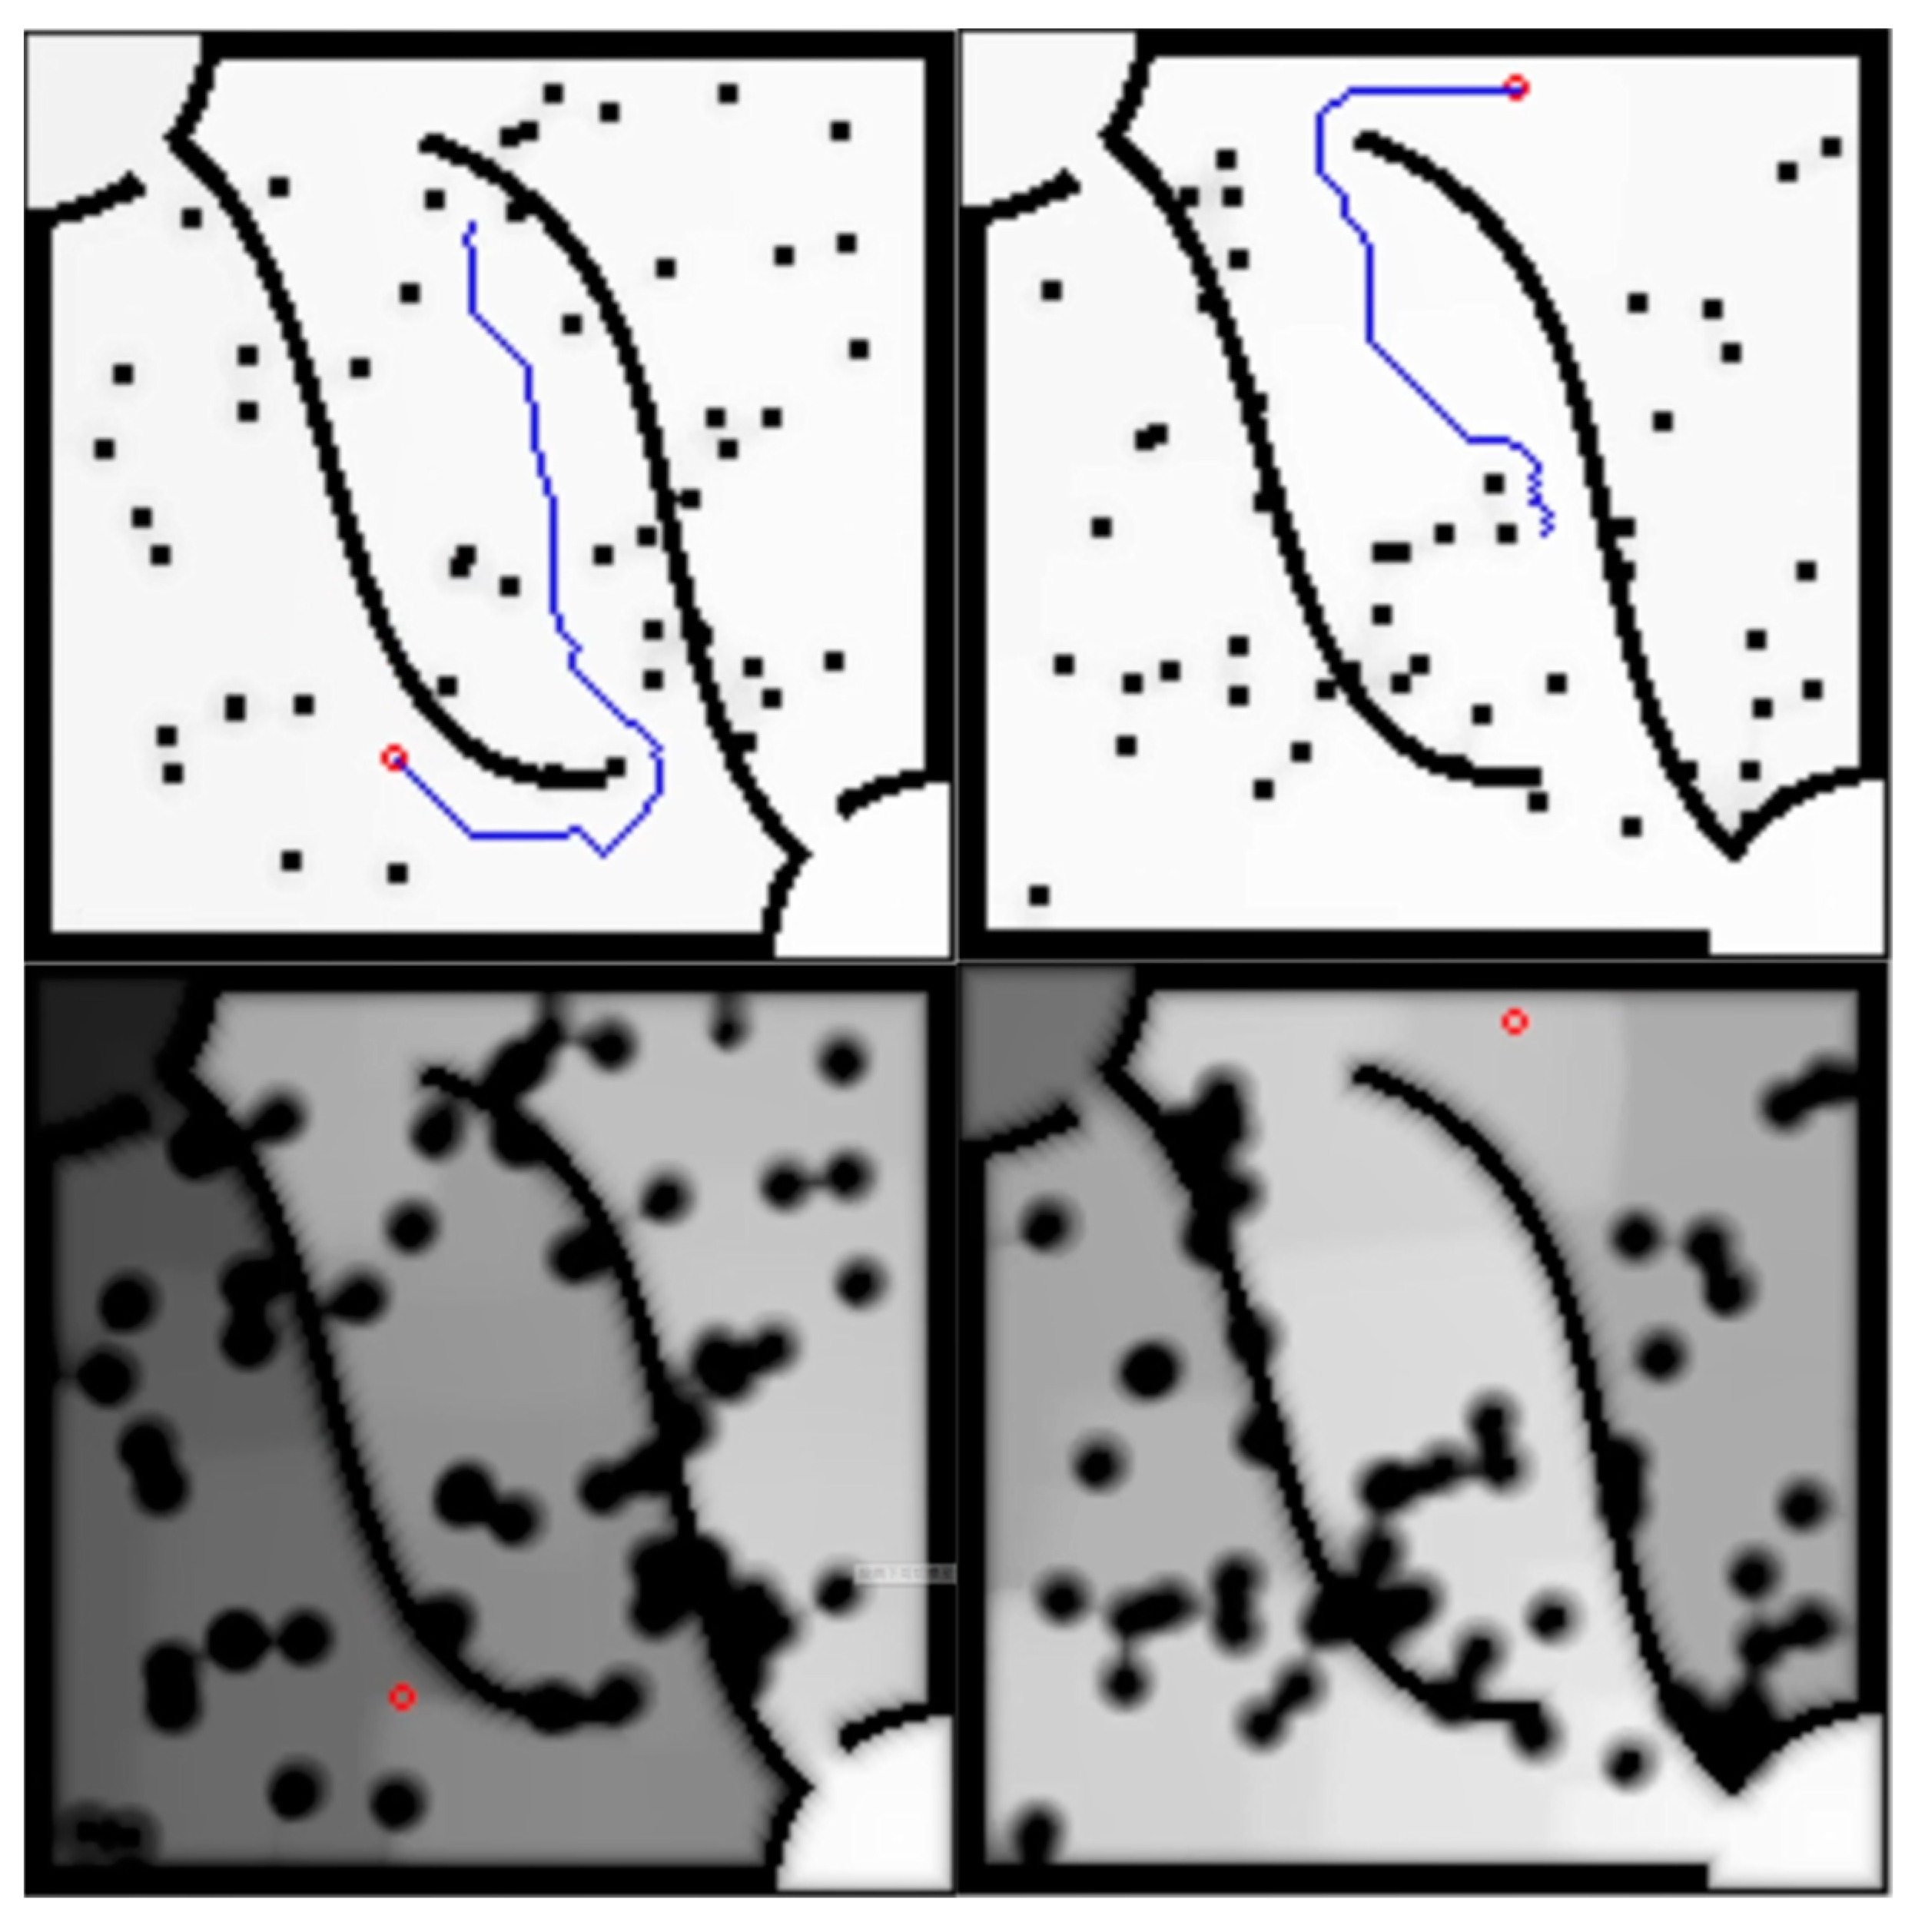
GitHub - XinJingHao/okayplan_ros: Real-time global path planning. It works as a short bridge between the article summary and the gallery section.
Looking at multiple sources also helps separate the main idea from small decorative details.
These notes are added so the page offers more than images and gives each visitor a clearer reason to keep reading.