Understanding variable acceleration is a cornerstone of A Level Mechanics, yet many students initially struggle with the shift from constant acceleration equations (SUVAT) to calculus-based methods. This guide distils the essential A Level maths notes on variable acceleration, focusing on the core principles needed to master this challenging topic.
The Conceptual Shift from Constant to Variable Acceleration
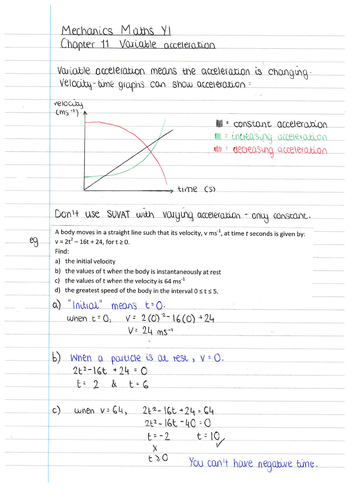
In pure Maths, you modelled motion with constant acceleration using the SUVAT equations. These rely on the assumption that a is a fixed value. Variable acceleration forces you to abandon these formulae. Here, acceleration is a function of time, a(t), or velocity, a(v), or displacement, a(x). The fundamental relationships become differential equations, and your toolkit is now calculus.
The core principle remains Newton's Second Law, but expressed as a differential equation. For one-dimensional motion, acceleration is the rate of change of velocity with respect to time. This is the first key relationship: a = dv/dt. Furthermore, velocity v is the rate of change of displacement s with respect to time. This is the second key relationship: v = ds/dt. This system of equations is the foundation for all problems involving non-uniform motion.

Connecting the Variables: The Chain Rule Application
A powerful technique for solving problems where acceleration is given as a function of velocity or displacement is the chain rule from pure mathematics. You can express acceleration as the derivative of velocity with respect to time. This is a crucial step in many exam questions.
The chain rule states that a = dv/dt. This can be rearranged to give a = v dv/ds. This form is particularly useful when acceleration is given as a function of s, as it allows you to integrate directly to find velocity as a function of displacement. This is a core technique you must master. This form a ds = v dv is very common. You can integrate both sides of this equation.
Problem-Solving Strategy: Typical Exam Question Structure
A typical exam question will provide you with a specific function for acceleration, a(t), a(v), or a(s), and initial conditions. The first step is always to set up the correct differential equation using the chain rule where necessary. For example, if given a(v), you would write dt = dv/a(v). If given a(s), you would write v dv = a(s) ds. If given a(t), you can integrate directly to find velocity v(t). If given a function for acceleration in terms of time, a(t), the process is a direct application of integration.

The second step is to integrate the differential equation to find a relationship between the variables, such as v(t) or v(s). The final step is to apply the initial conditions to determine the constant of integration, C. This will give you the specific solution for the problem. For example, a question might state that a particle starts from rest at a specific point, which provides initial conditions for both velocity and displacement. This information is crucial for determining the constant of integration, ensuring your solution is complete and specific to the scenario. Always check your final solution by substituting the initial conditions back into the derived equation.
Differentiating Velocity to Find Acceleration
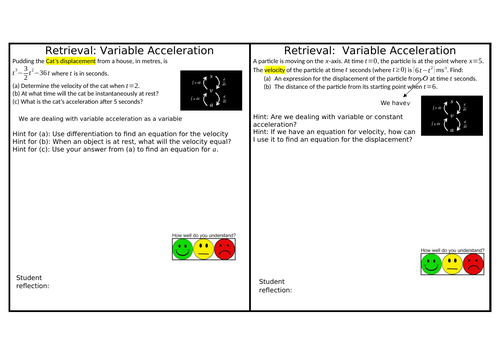
This relationship holds true regardless of how complex the function for displacement might be. For a displacement function s(t), differentiating with respect to time gives you the velocity function v(t). For a velocity function v(t), differentiating with respect to time gives you the acceleration function a(t). For an acceleration function a(t), integrating with respect to time gives you the velocity function v(t). For a velocity function v(t), integrating with respect to time gives you the displacement function s(t). These are the inverse operations of differentiation and integration and are critical for solving motion problems.
Worked Example: Particle with Deceleration Proportional to Velocity Squared
A classic exam scenario involves a particle moving in a straight line with deceleration proportional to the square of its velocity, i.e., a = -kv2. This is a classic example where the chain rule is essential for solving the problem. To find velocity as a function of displacement (or vice versa), one must use the relationship a = v dv/ds. Any other setup, such as using a = dv/dt directly, would not lead to a soluble equation for v(s).
Setting up the differential equation using the chain rule gives-kv2 = v dv/ds. This separates the variables, allowing for integration. This simplifies to -k ds = (1/v) dv. Integrating both sides yields -ks = ln|v| + C. Applying initial conditions (e.g., when s=0, v=u) gives C = -ln|u|. Substituting back, the final solution is v = u e-ks. This shows an exponential decay of velocity with displacement, a result that is counter-intuitive to students expecting linear change. Sketches of v(s) are crucial for visual understanding.
Displacement-Time Graphs and Problem-Solving
Acceleration is the second derivative of displacement. Particle motion questions are often set in a real-world context, such as a car braking or a ball thrown upwards. Interpreting the direction of vectors and the meaning of negative values in each context is essential. Negative acceleration can mean deceleration in the positive direction or acceleration in the negative direction. Displacement-time (s/t) graphs are powerful tools for visualising this.
The gradient of a displacement-time (s/t) graph at any point gives the instantaneous velocity. Similarly, the gradient of a velocity-time (v/t) graph at any point gives the instantaneous acceleration. The area under a velocity-time (v/t) graph between two time points gives the displacement. The area under an acceleration-time graph between two time points gives the change in velocity. These geometric interpretations are as important as the calculus for a full understanding of motion.
Conclusion: Building Fluency with Differential Equations
Variable acceleration problems are fundamentally about setting up and solving differential equations. The key is to identify the given function for acceleration and choose the correct form of the equation. Practice is essential. Work through past paper questions, focusing on the setup of the differential equation. This is where most marks are lost. A clear, methodical approach will build your confidence and ensure you can tackle any problem involving non-uniform motion.