@foxglove/rosbag @foxglove/rosbag @foxglove/rosbag is a node.js & browser compatible module for reading rosbag binary data files. Installation npm install @foxglove/rosbag or yarn add @foxglove/rosbag Quick start The most common way to interact with a rosbag is to read data records for a specific set of topics. Load and analyze rosbag files.
Foxglove supports both live streaming and postmortem analysis using rosbag files. Developers can: Upload.bag files to replay telemetry data. Debug complex issues by scrubbing through time.

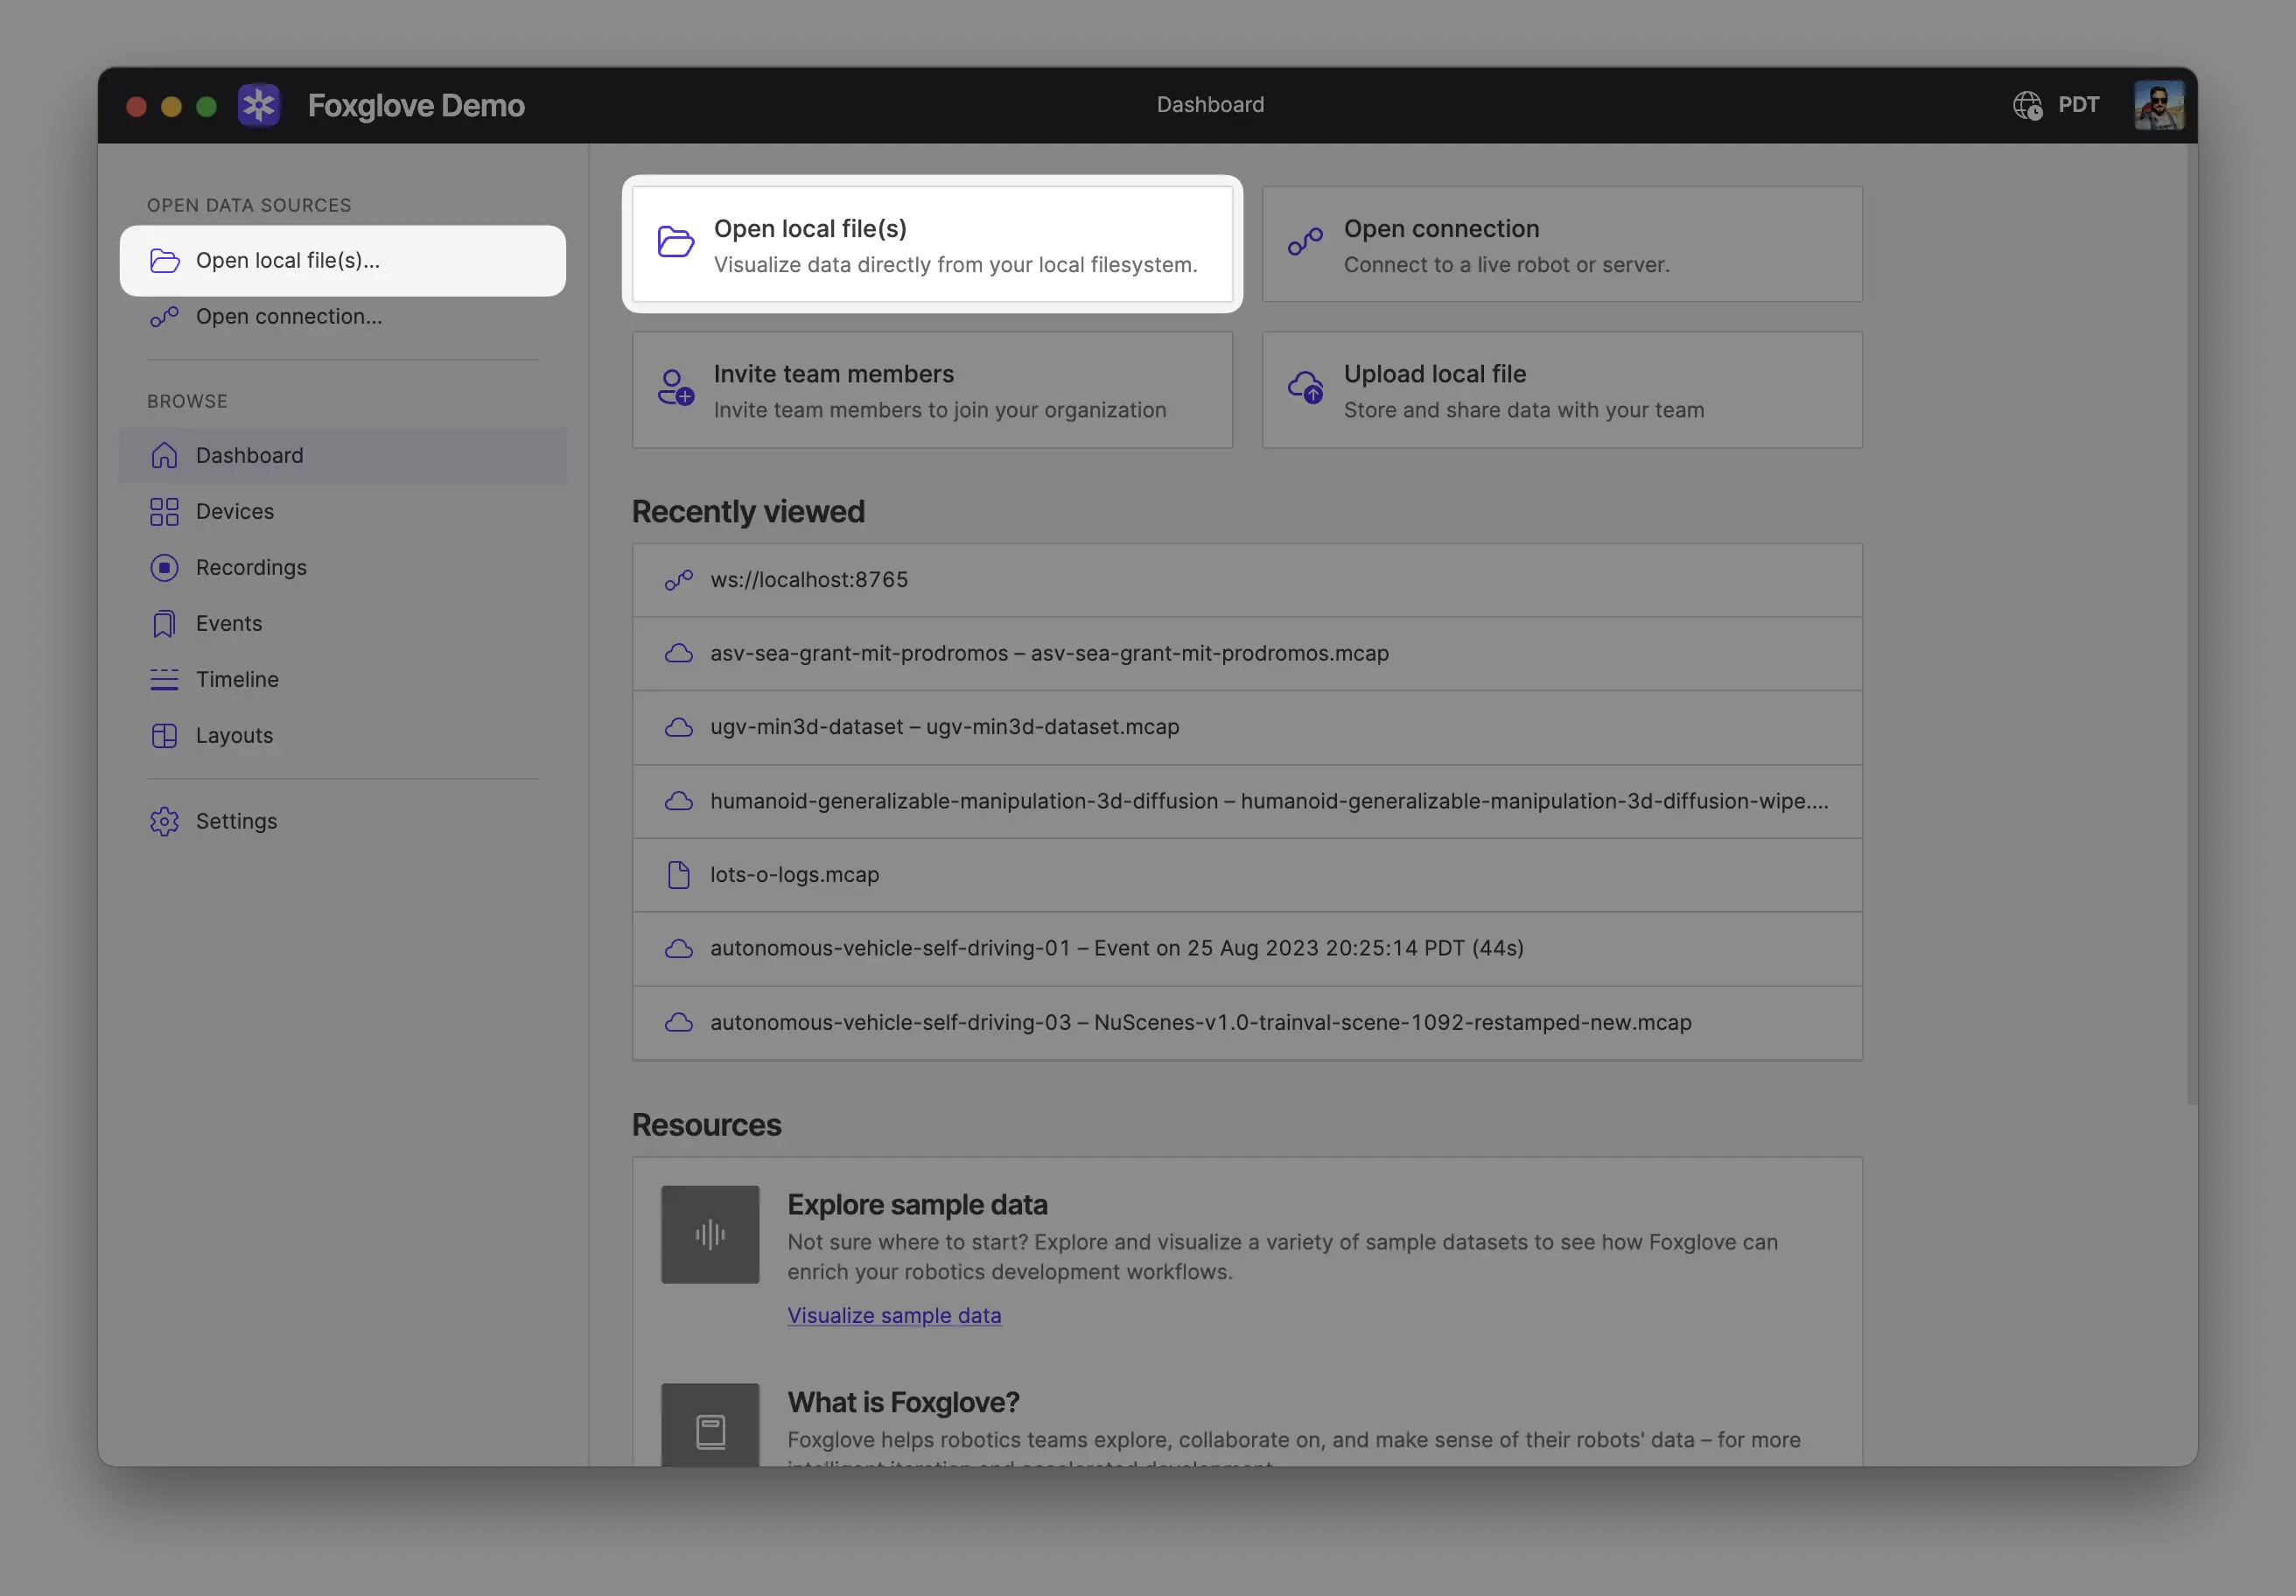
The rosbag format encodes type information for topics, and rosbag reads this type information and parses the data records into JavaScript objects and arrays. Here is an example of reading messages from a rosbag in node.js. Opening a rosbag Foxglove can open.bag files natively.

If you don't have a.bag file, use the rosbag package to record data. 1. Record data With your ROS stack running, record data on your robot: rosbag record -a --duration=30.
For ROS: @foxglove/ros1 - TypeScript implementation of ROS 1 protocol with a pluggable transport layer @foxglove/rosbag - ROS 1 bag reader and writer abstract implementation @foxglove/rosbag2 - ROS 2 bag reader and writer abstract implementation @foxglove/rosbag2. @foxglove/rosbag2 ROS2 (Robot Operating System) legacy SQLite bag reader abstract implementation NOTICE: The SQLite rosbag2 recording format has been replaced by MCAP. This package is only useful for reading legacy rosbag2.db3 files.

Developers: Use @foxglove/rosbag2-node or @foxglove/rosbag2. ROS2 (Robot Operating System) legacy SQLite bag reader abstract implementation NOTICE: The SQLite rosbag2 recording format has been replaced by MCAP. This package is only useful for reading legacy rosbag2.db3 files.
Developers: Use @foxglove/rosbag2-node or @foxglove/rosbag2. Today, we're excited to announce that Foxglove Studio now supports loading ROS 2 bags for playback and visualization. With v0.13.0, a new data source option (ROS 2 Bag Folder (local)) will be available in the sidebar's Connection tab: With this option, you can load rosbag2 files for playback, in the same way you can currently load rosbag files.
We also recently released a web build of. Documentation for @foxglove/rosbag messageIterator message Iterator (opt?: MessageIteratorOpt): MessageIterator Parameters Optional opt: MessageIteratorOpt Optional opt: MessageIteratorOpt Returns MessageIterator Defined in Bag.ts:81 Defined in Bag.ts:81. Discover the top tools for rosbag visualization in 2025.
Learn how to use Foxglove, RViz, and other open.